H-855.H2A Novità!
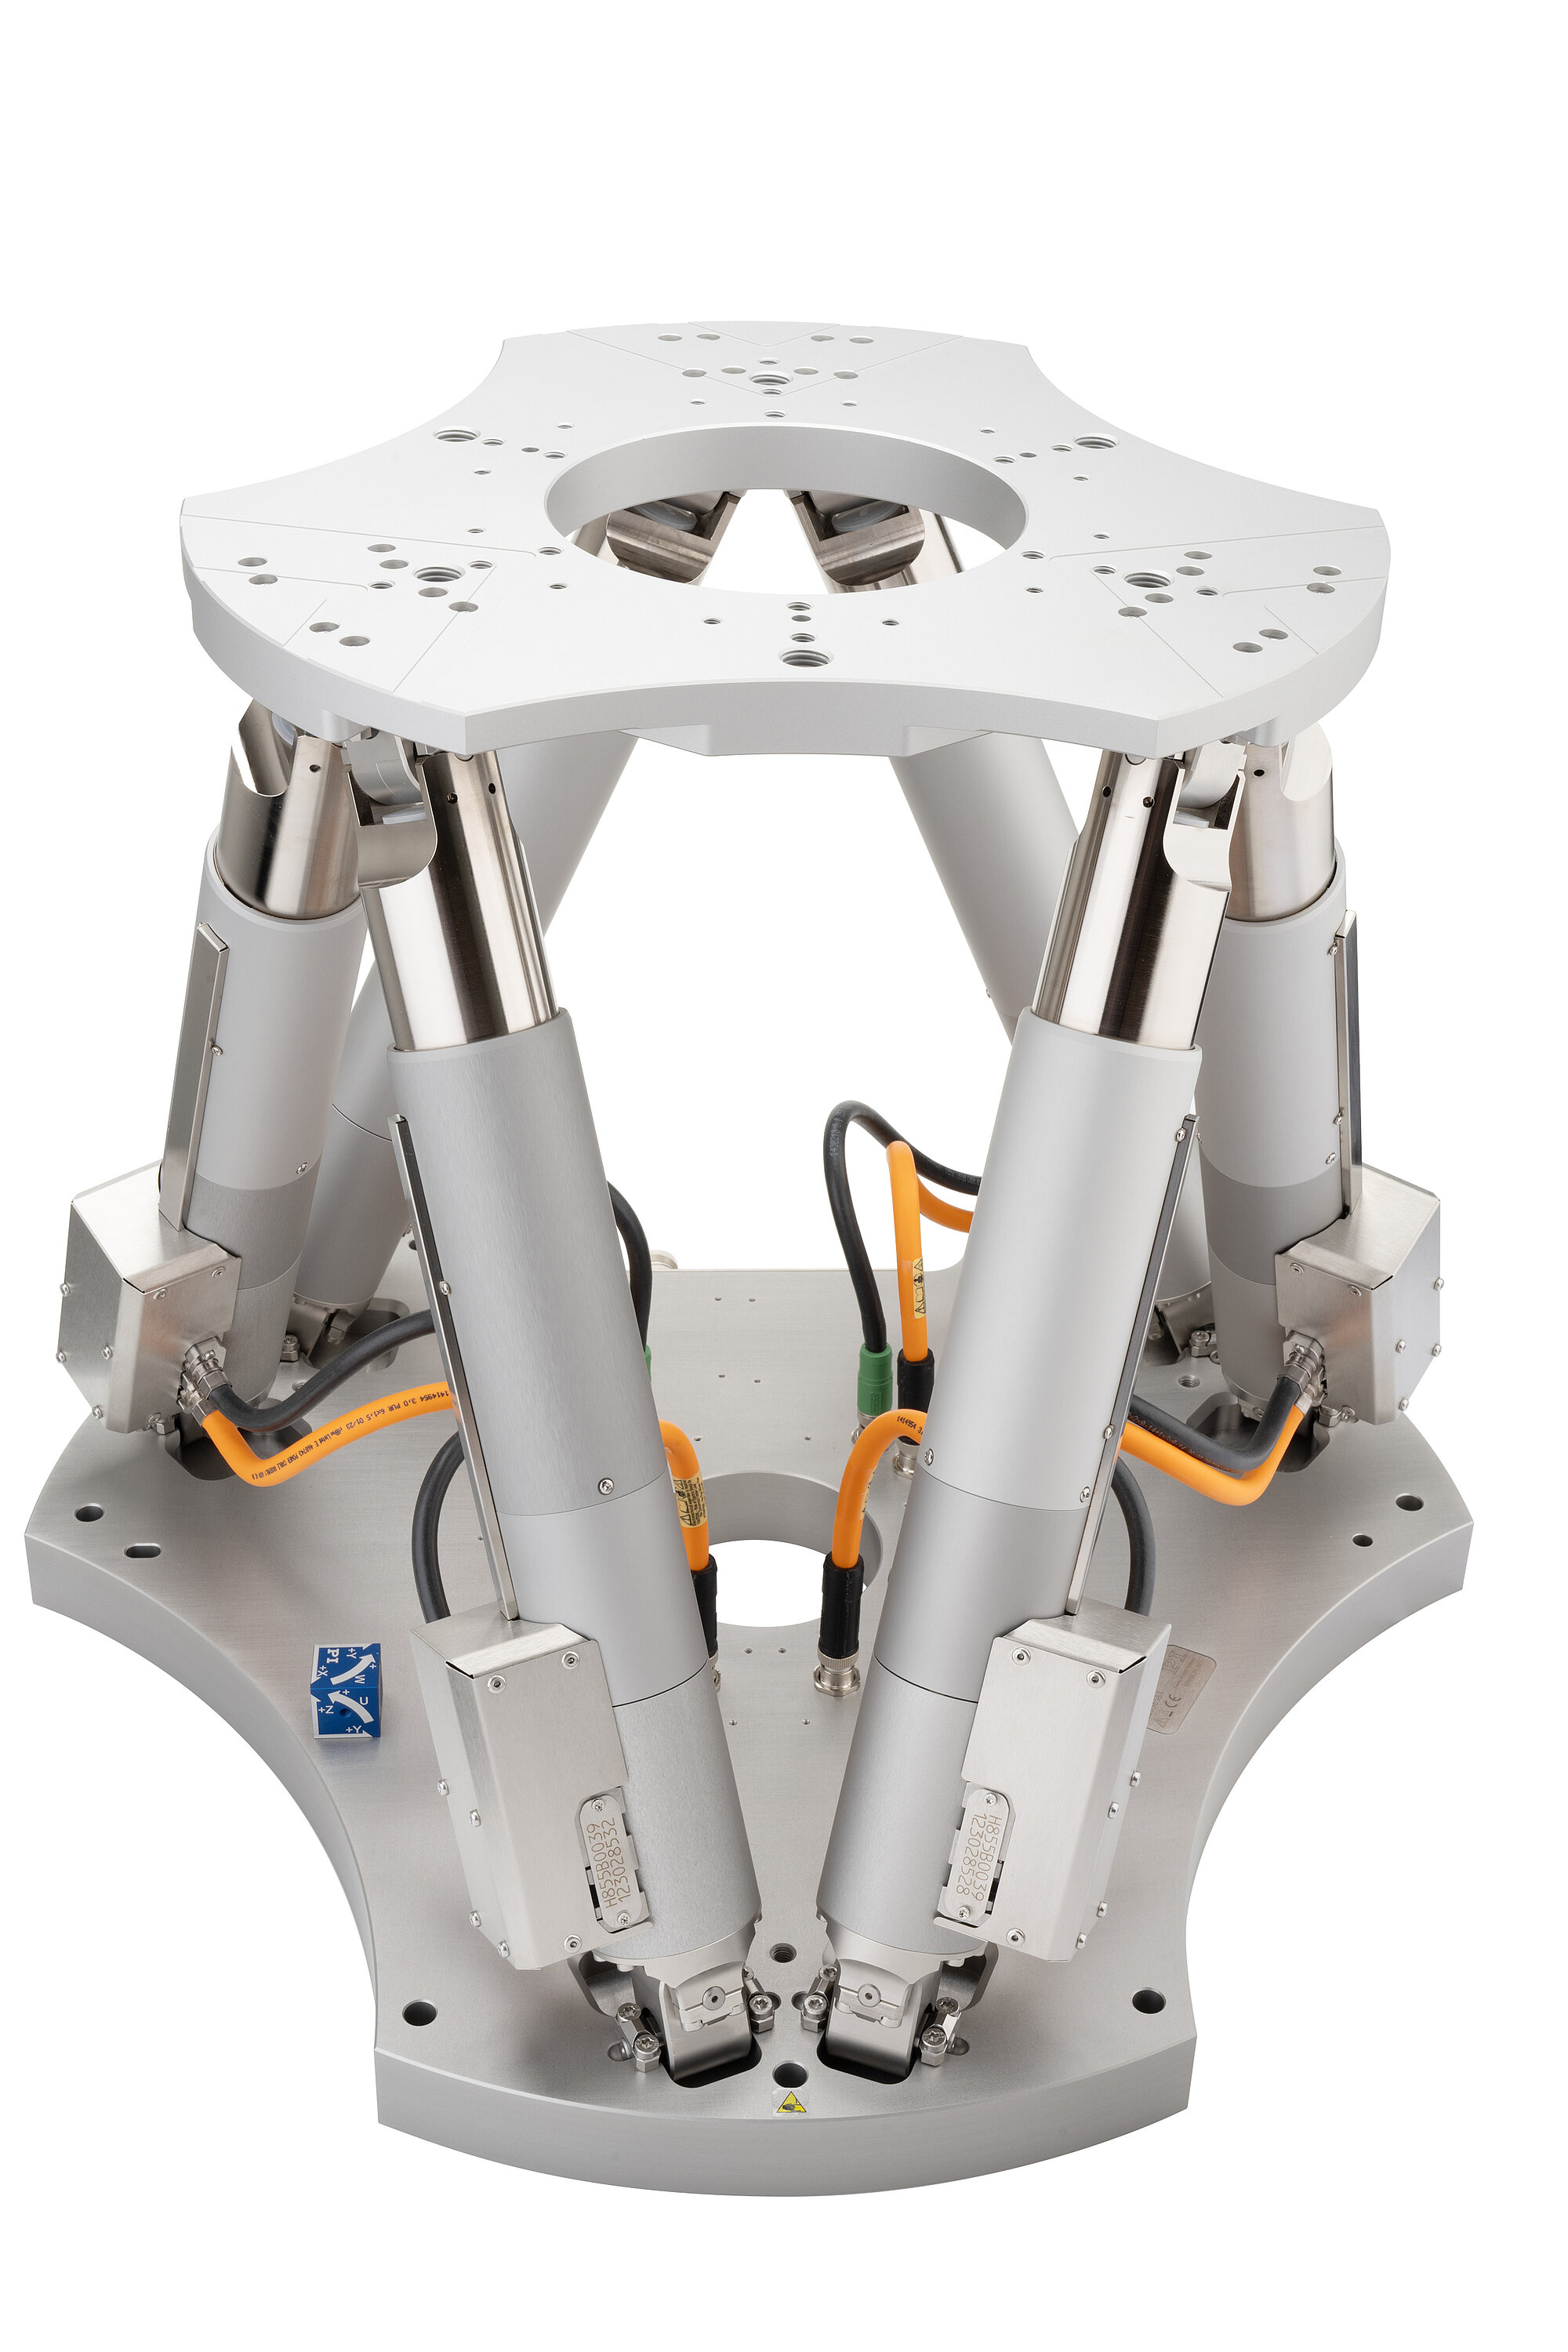
High-load hexapod; brushless DC gear motor; absolute encoder; 500 kg payload; 0.5 mm/s maximum velocity; 3 m cable set consisting of data and power supply cables
H-855.G2A0B
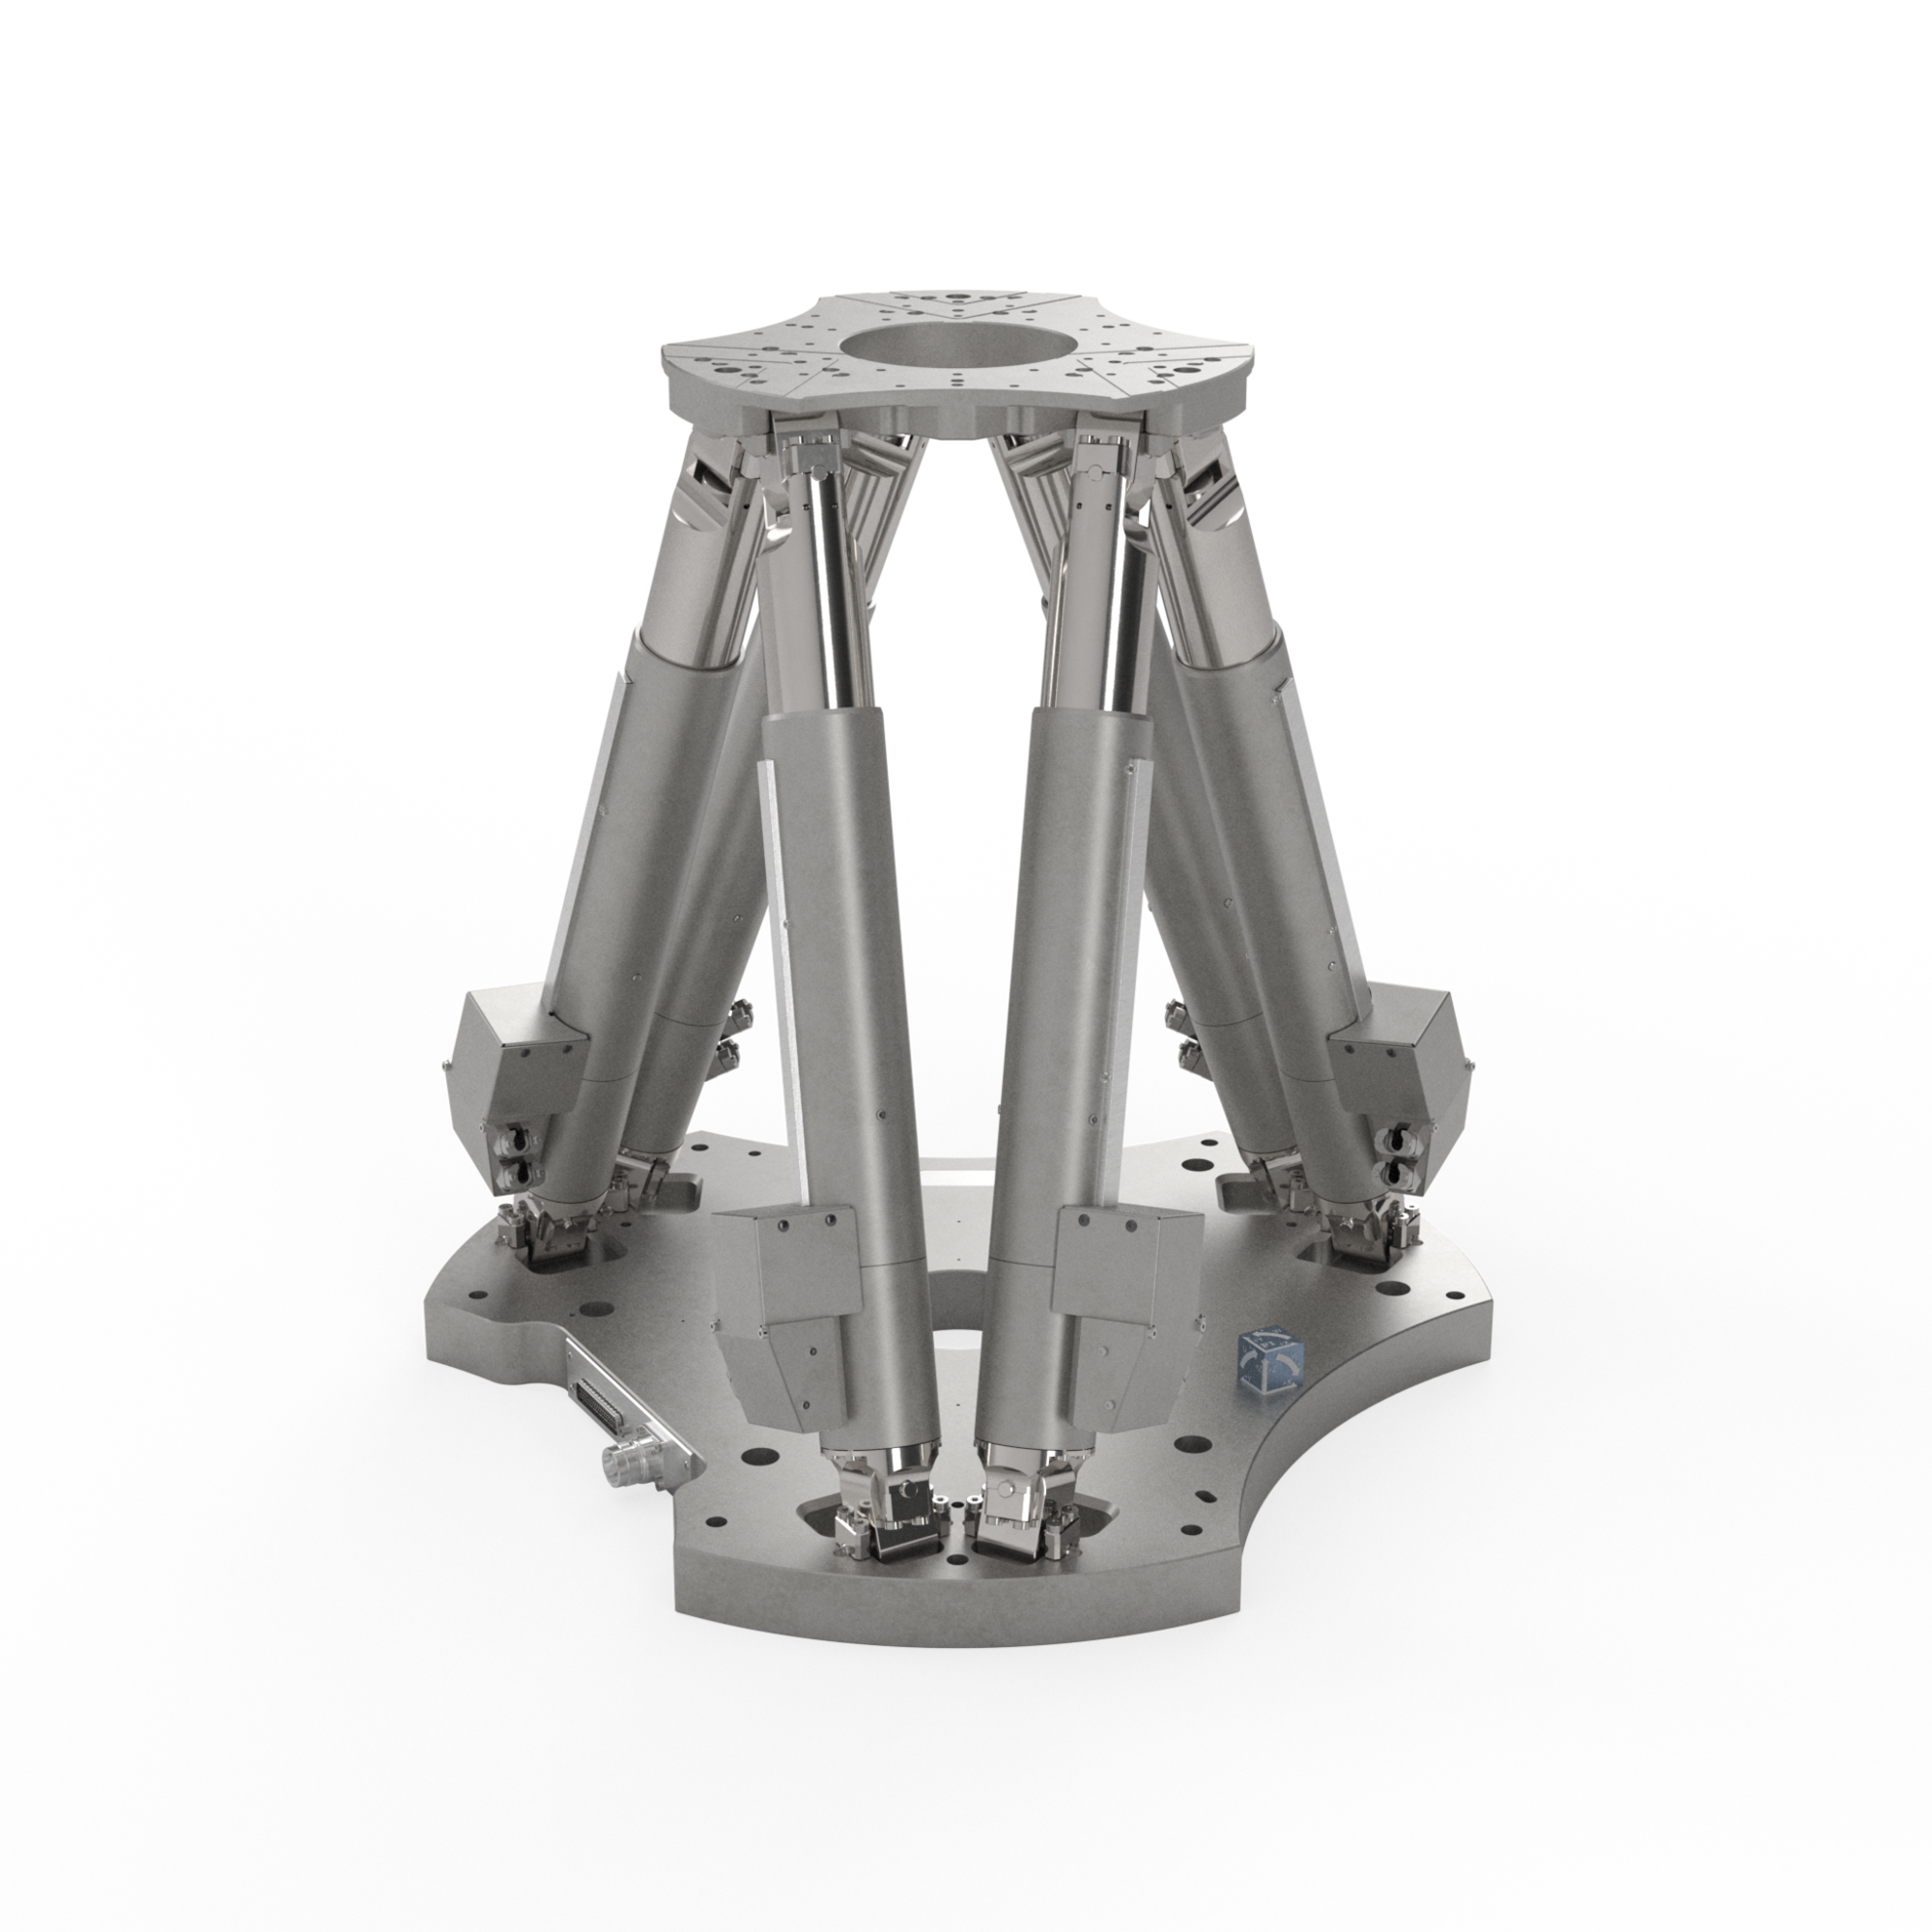
H-855.H2AL
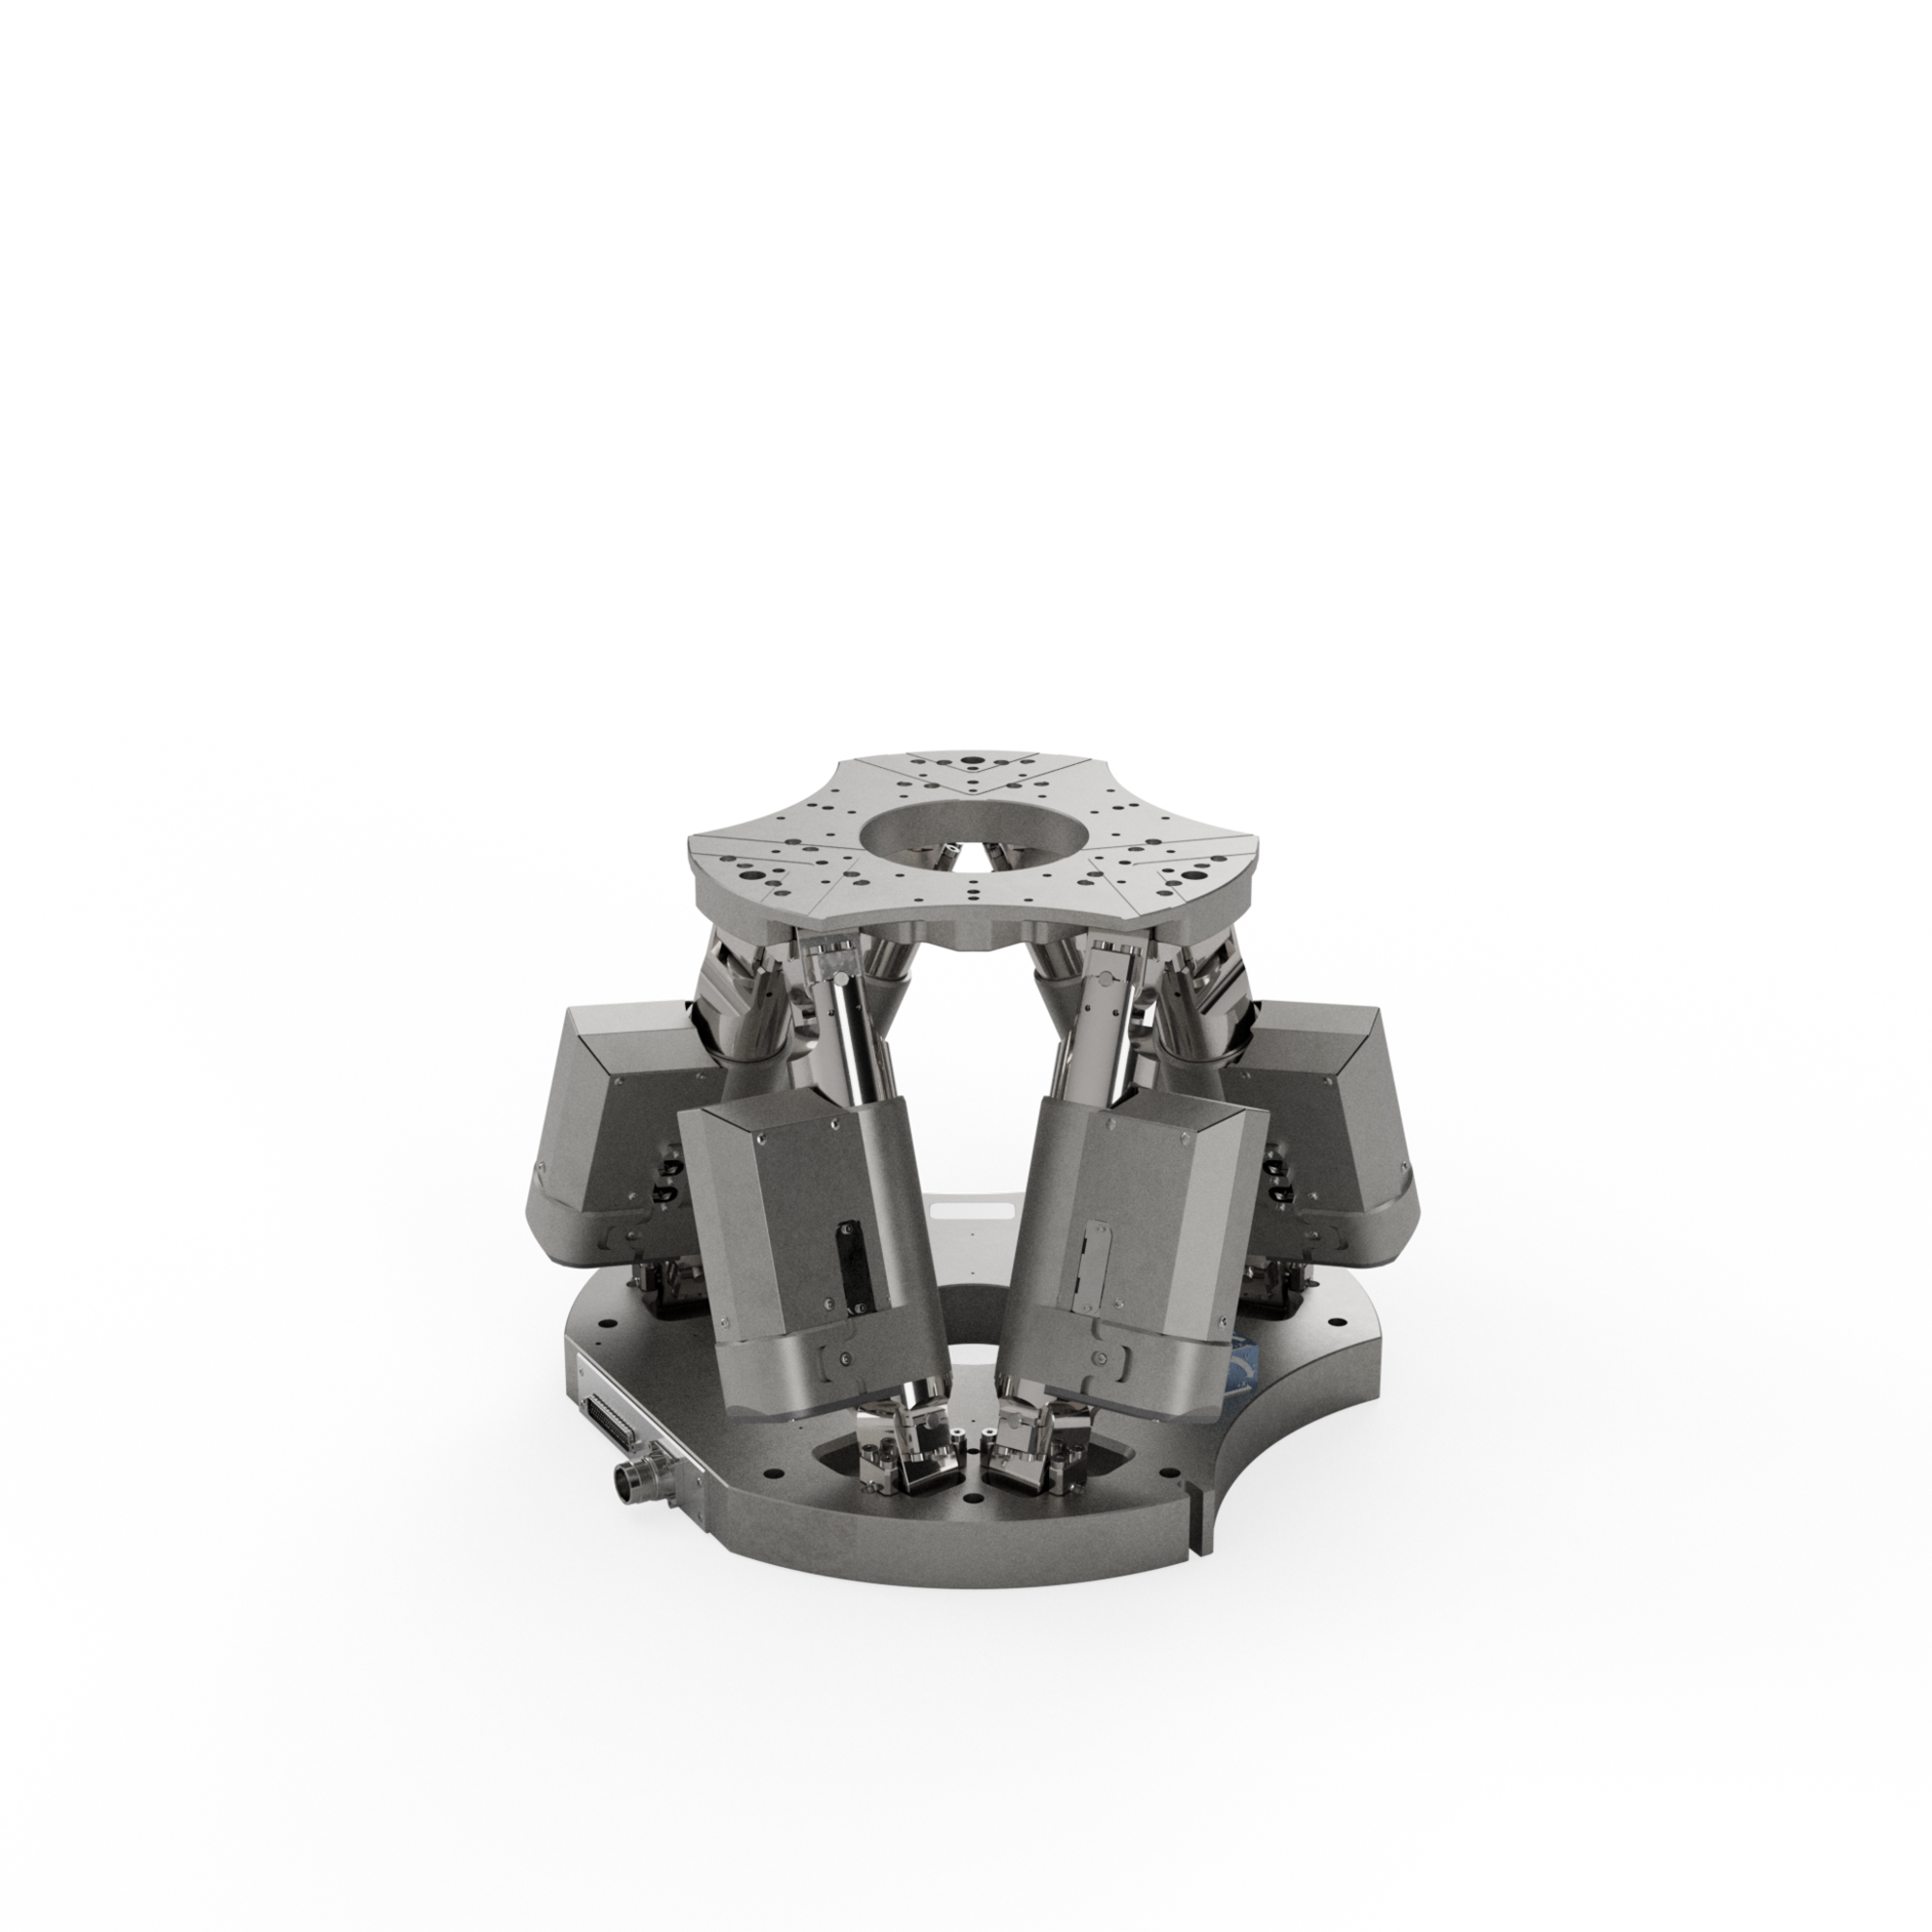
H-855.H2AC
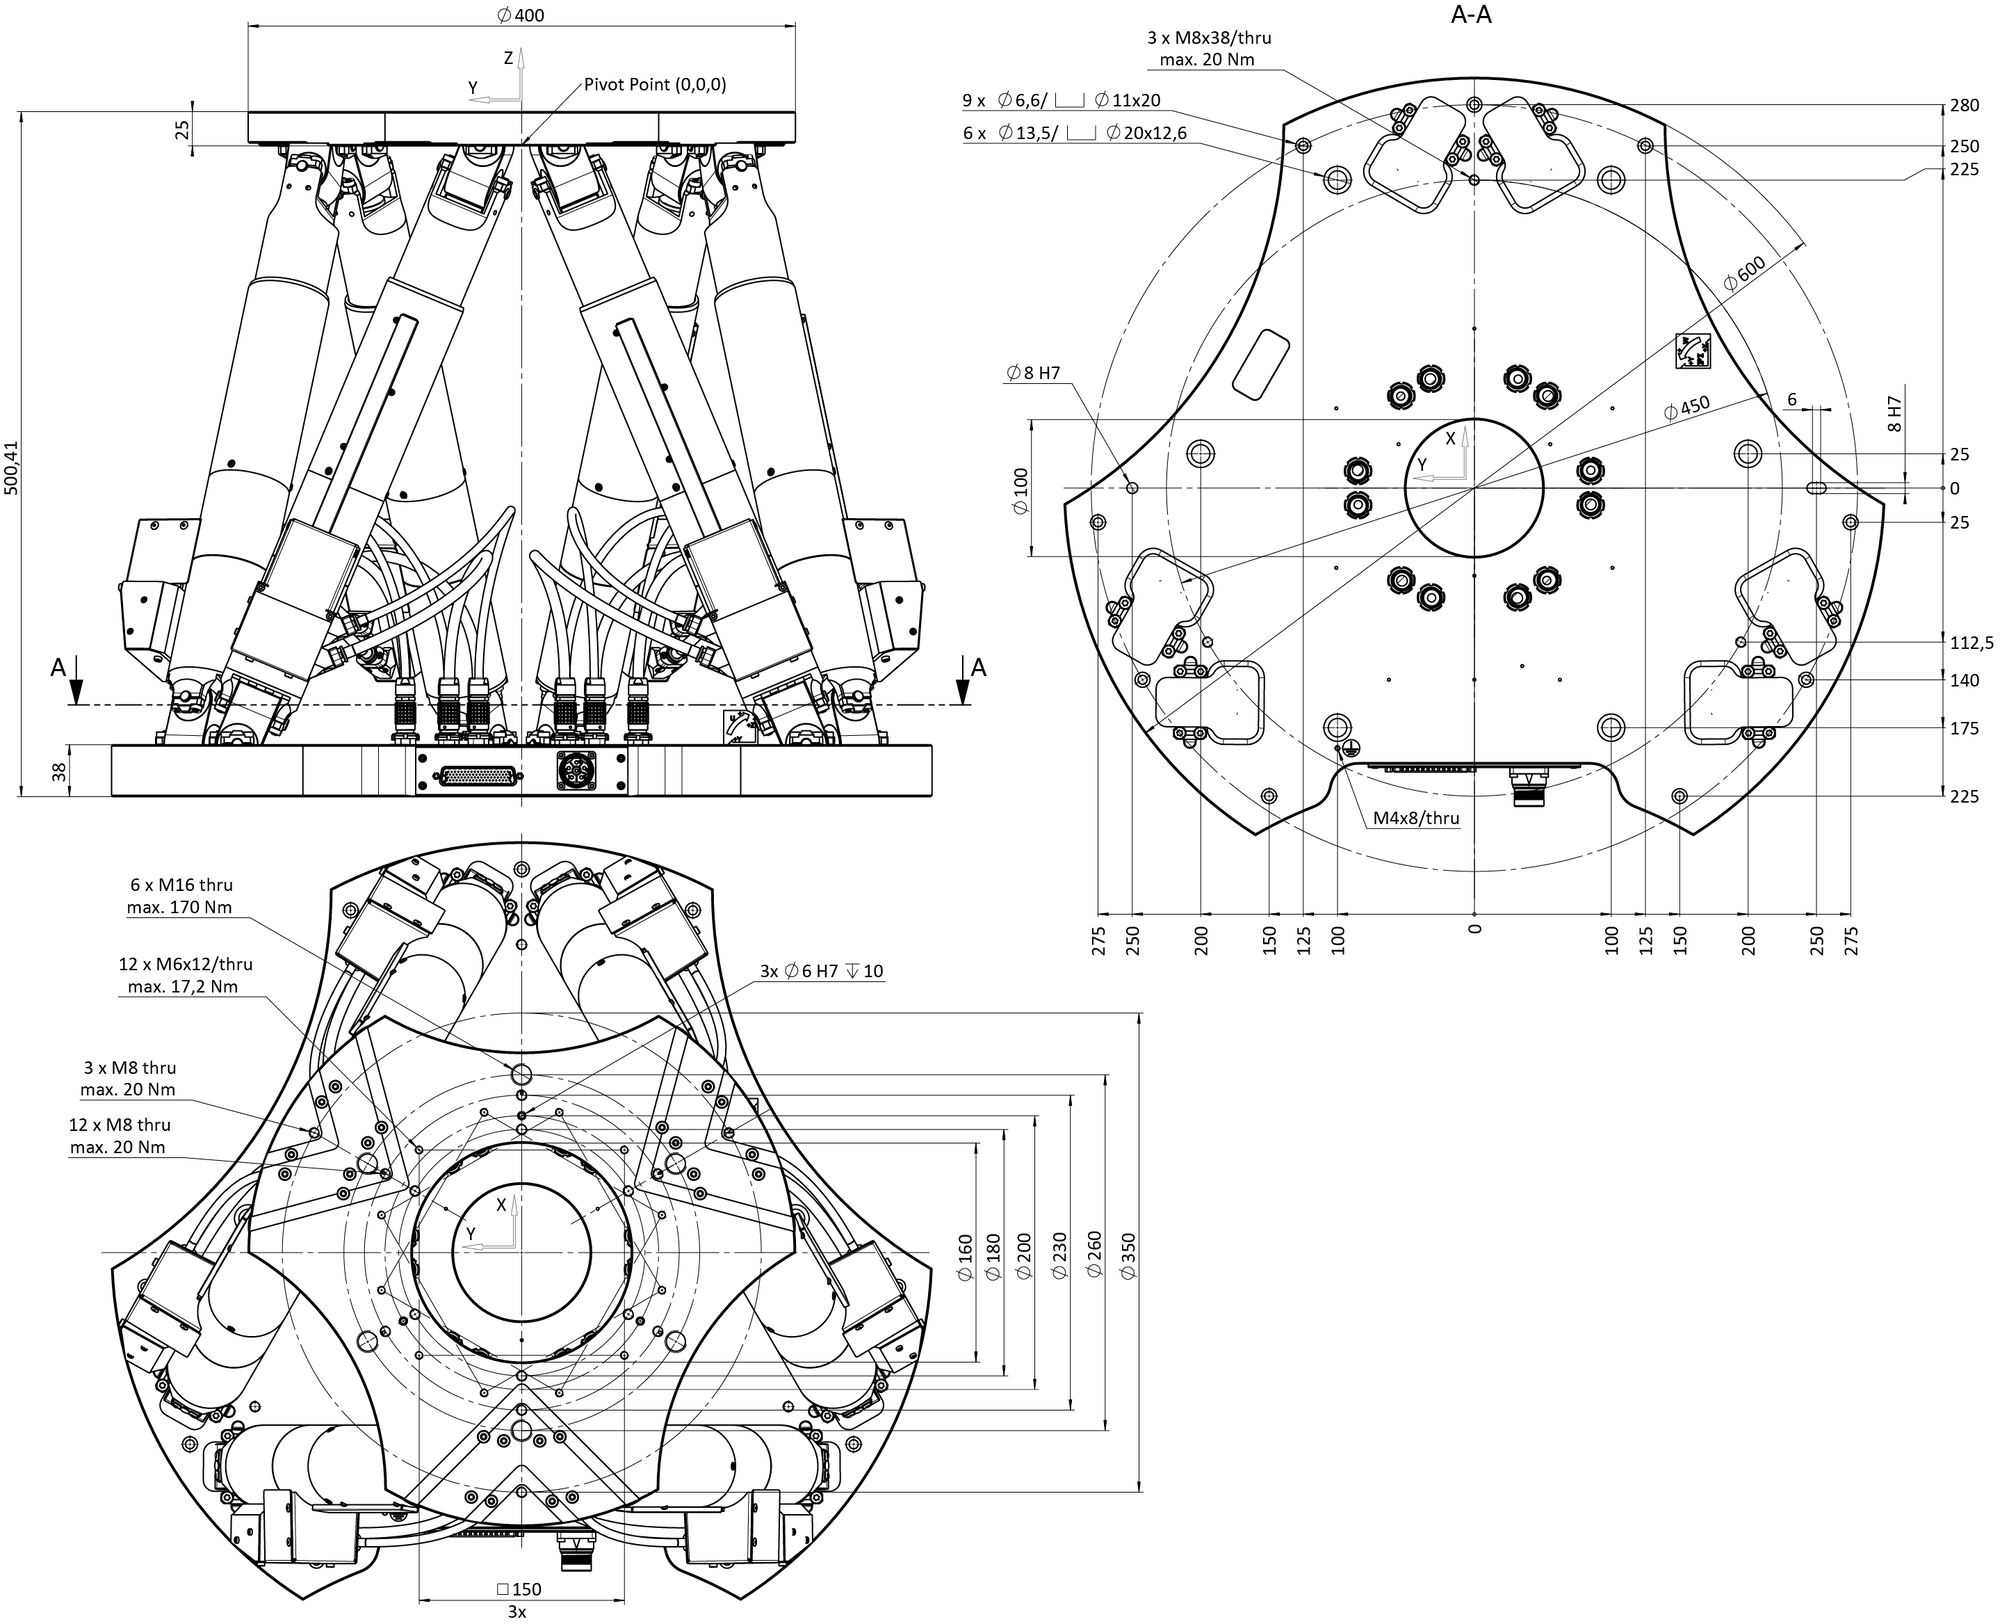
H-855.H2A, dimensions in mm, at the zero position of the nominal travel range
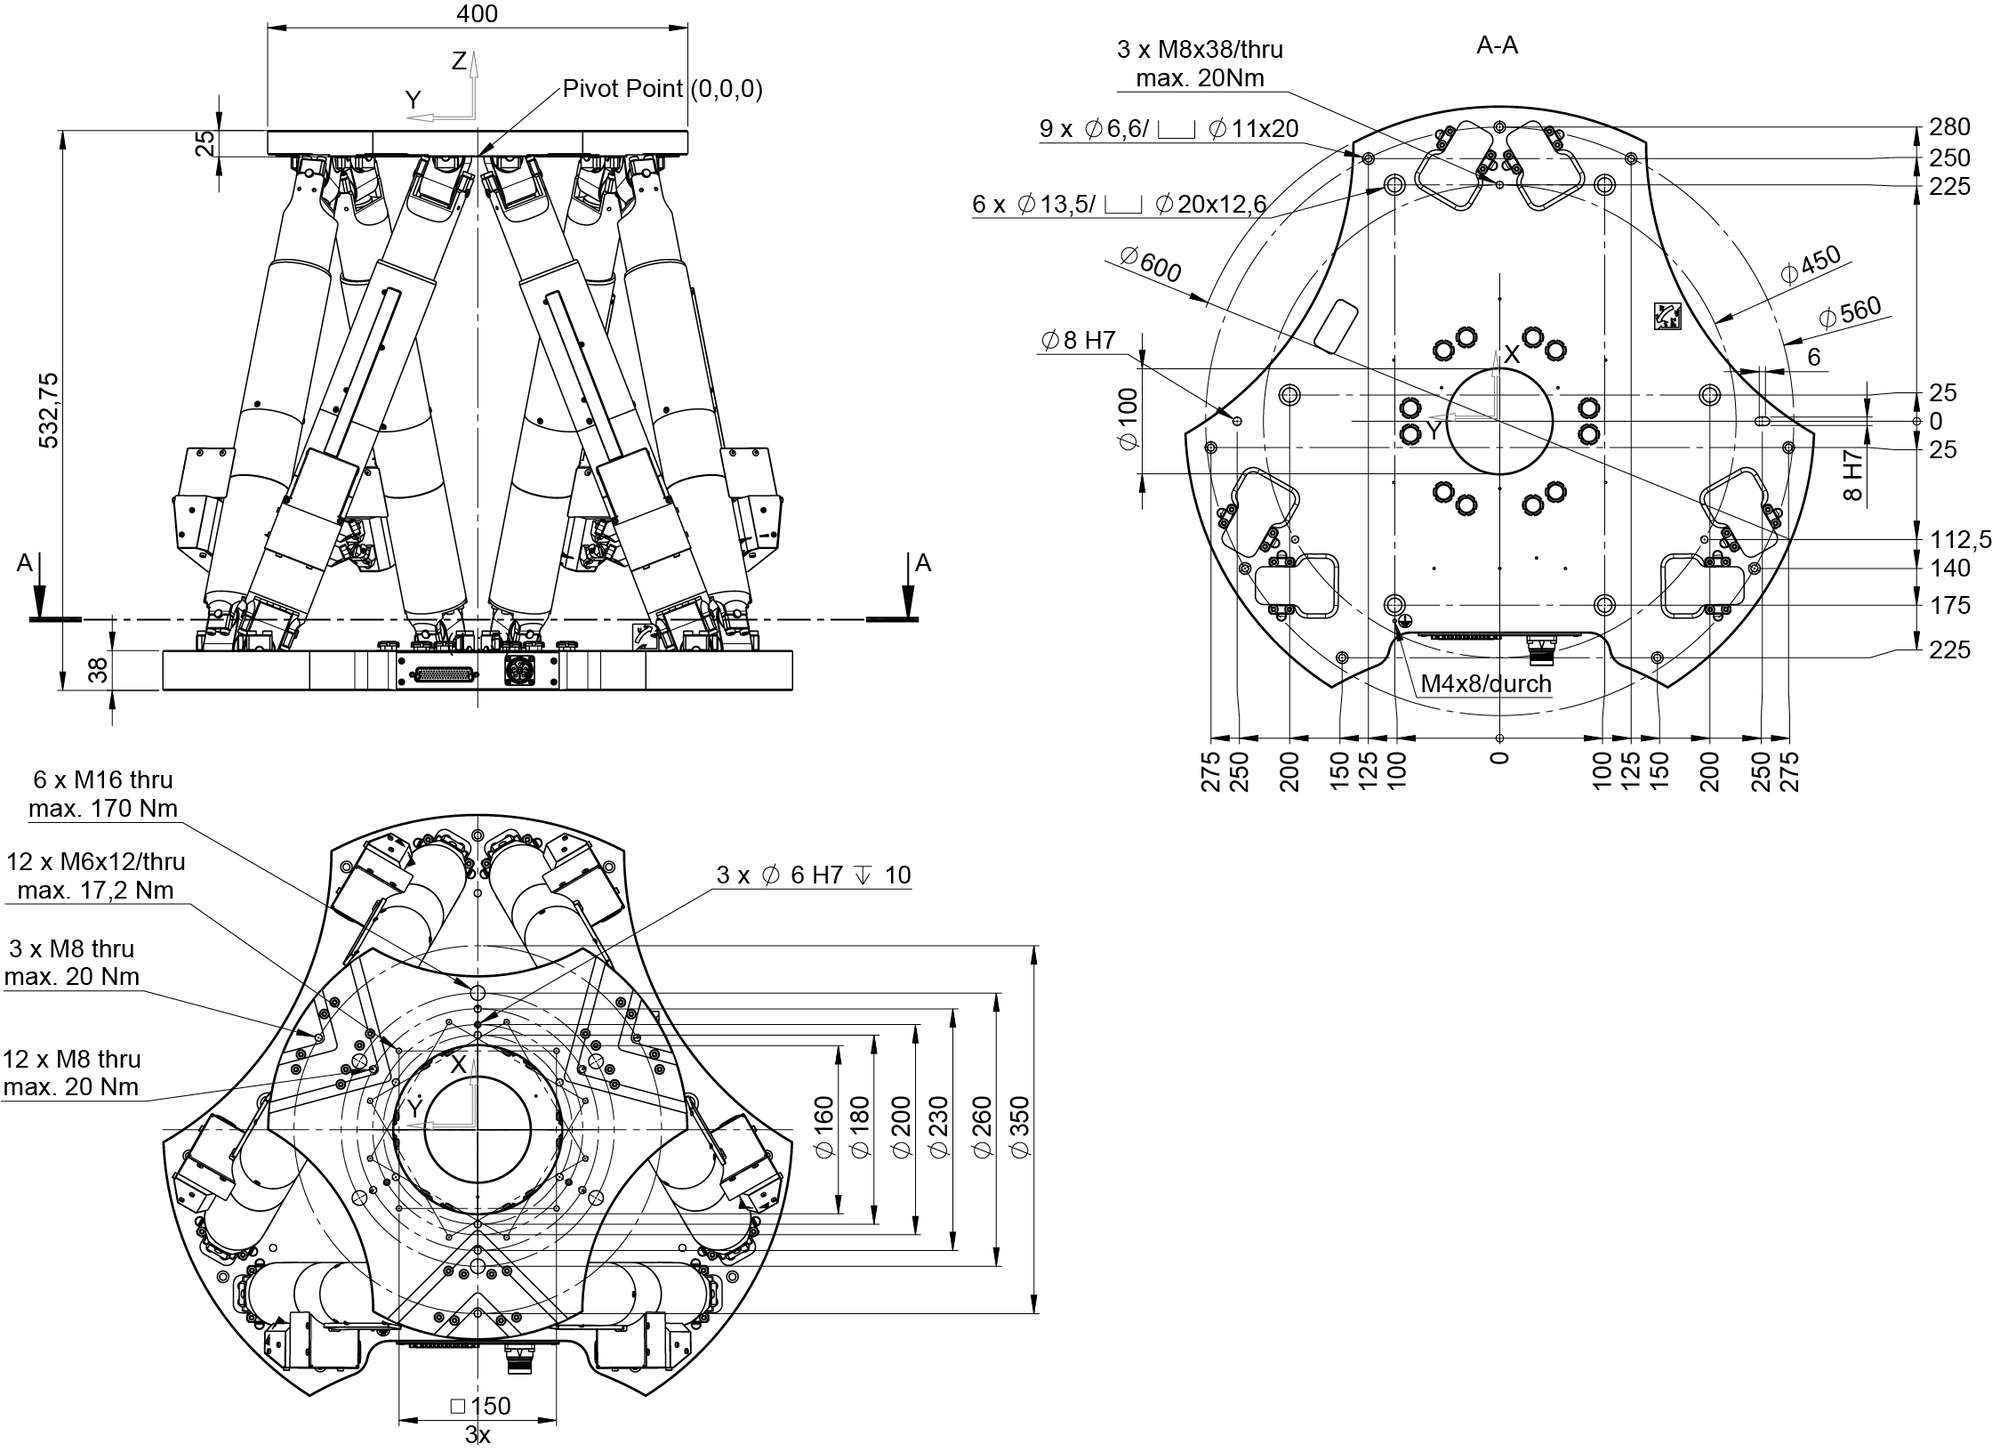
H-855.G2A0B, dimensions in mm, at the zero position of the nominal travel range
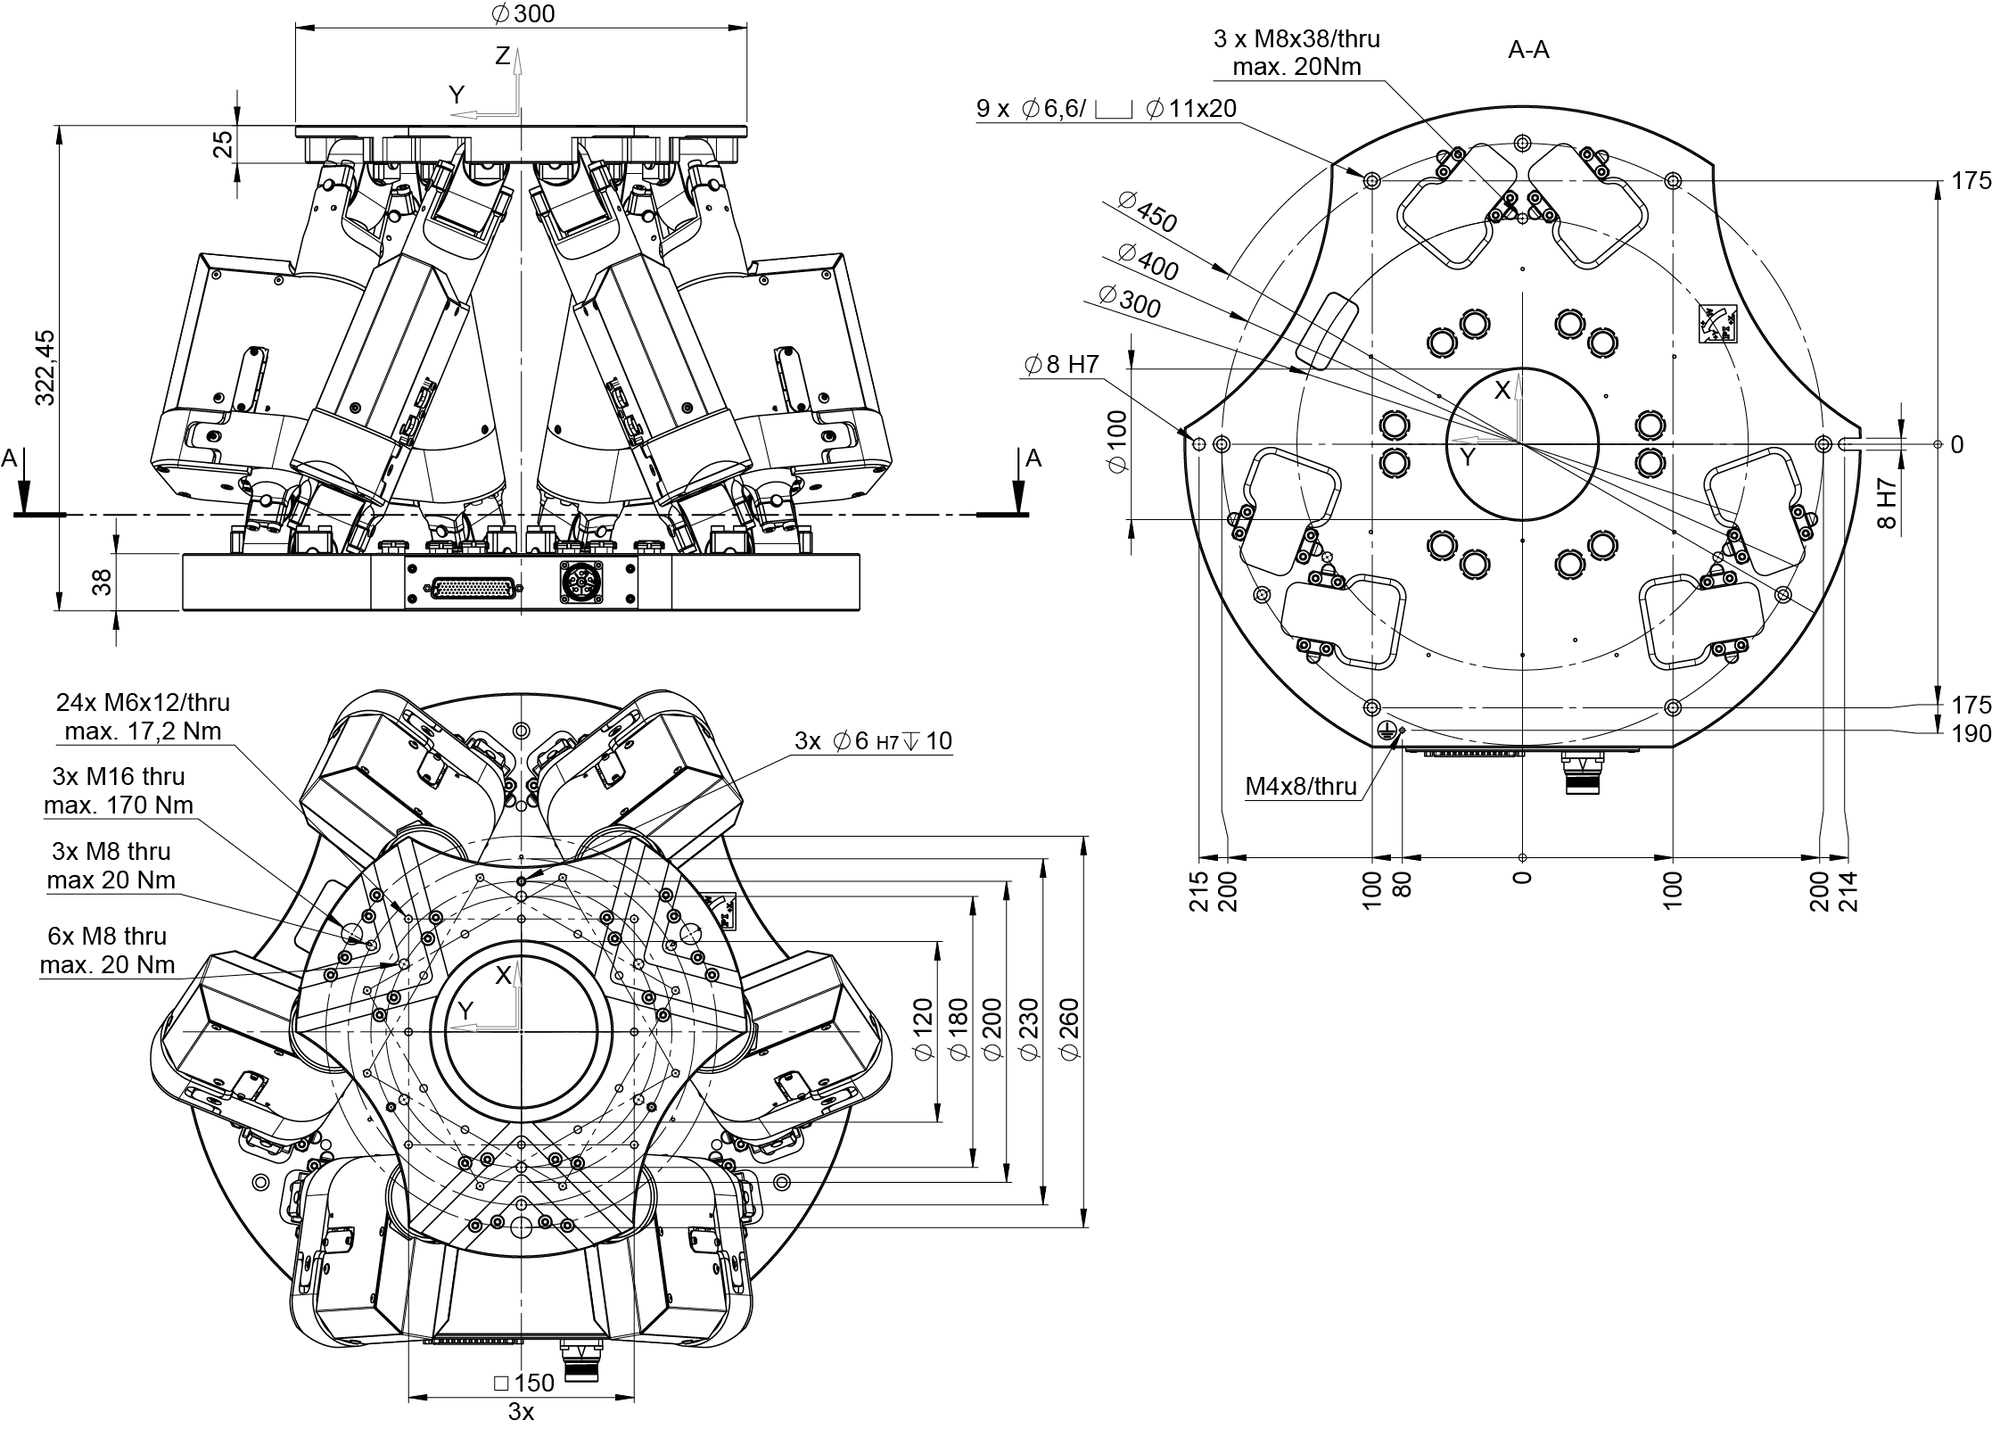
H-855.H2AC, dimensions in mm, at the zero position of the nominal travel range
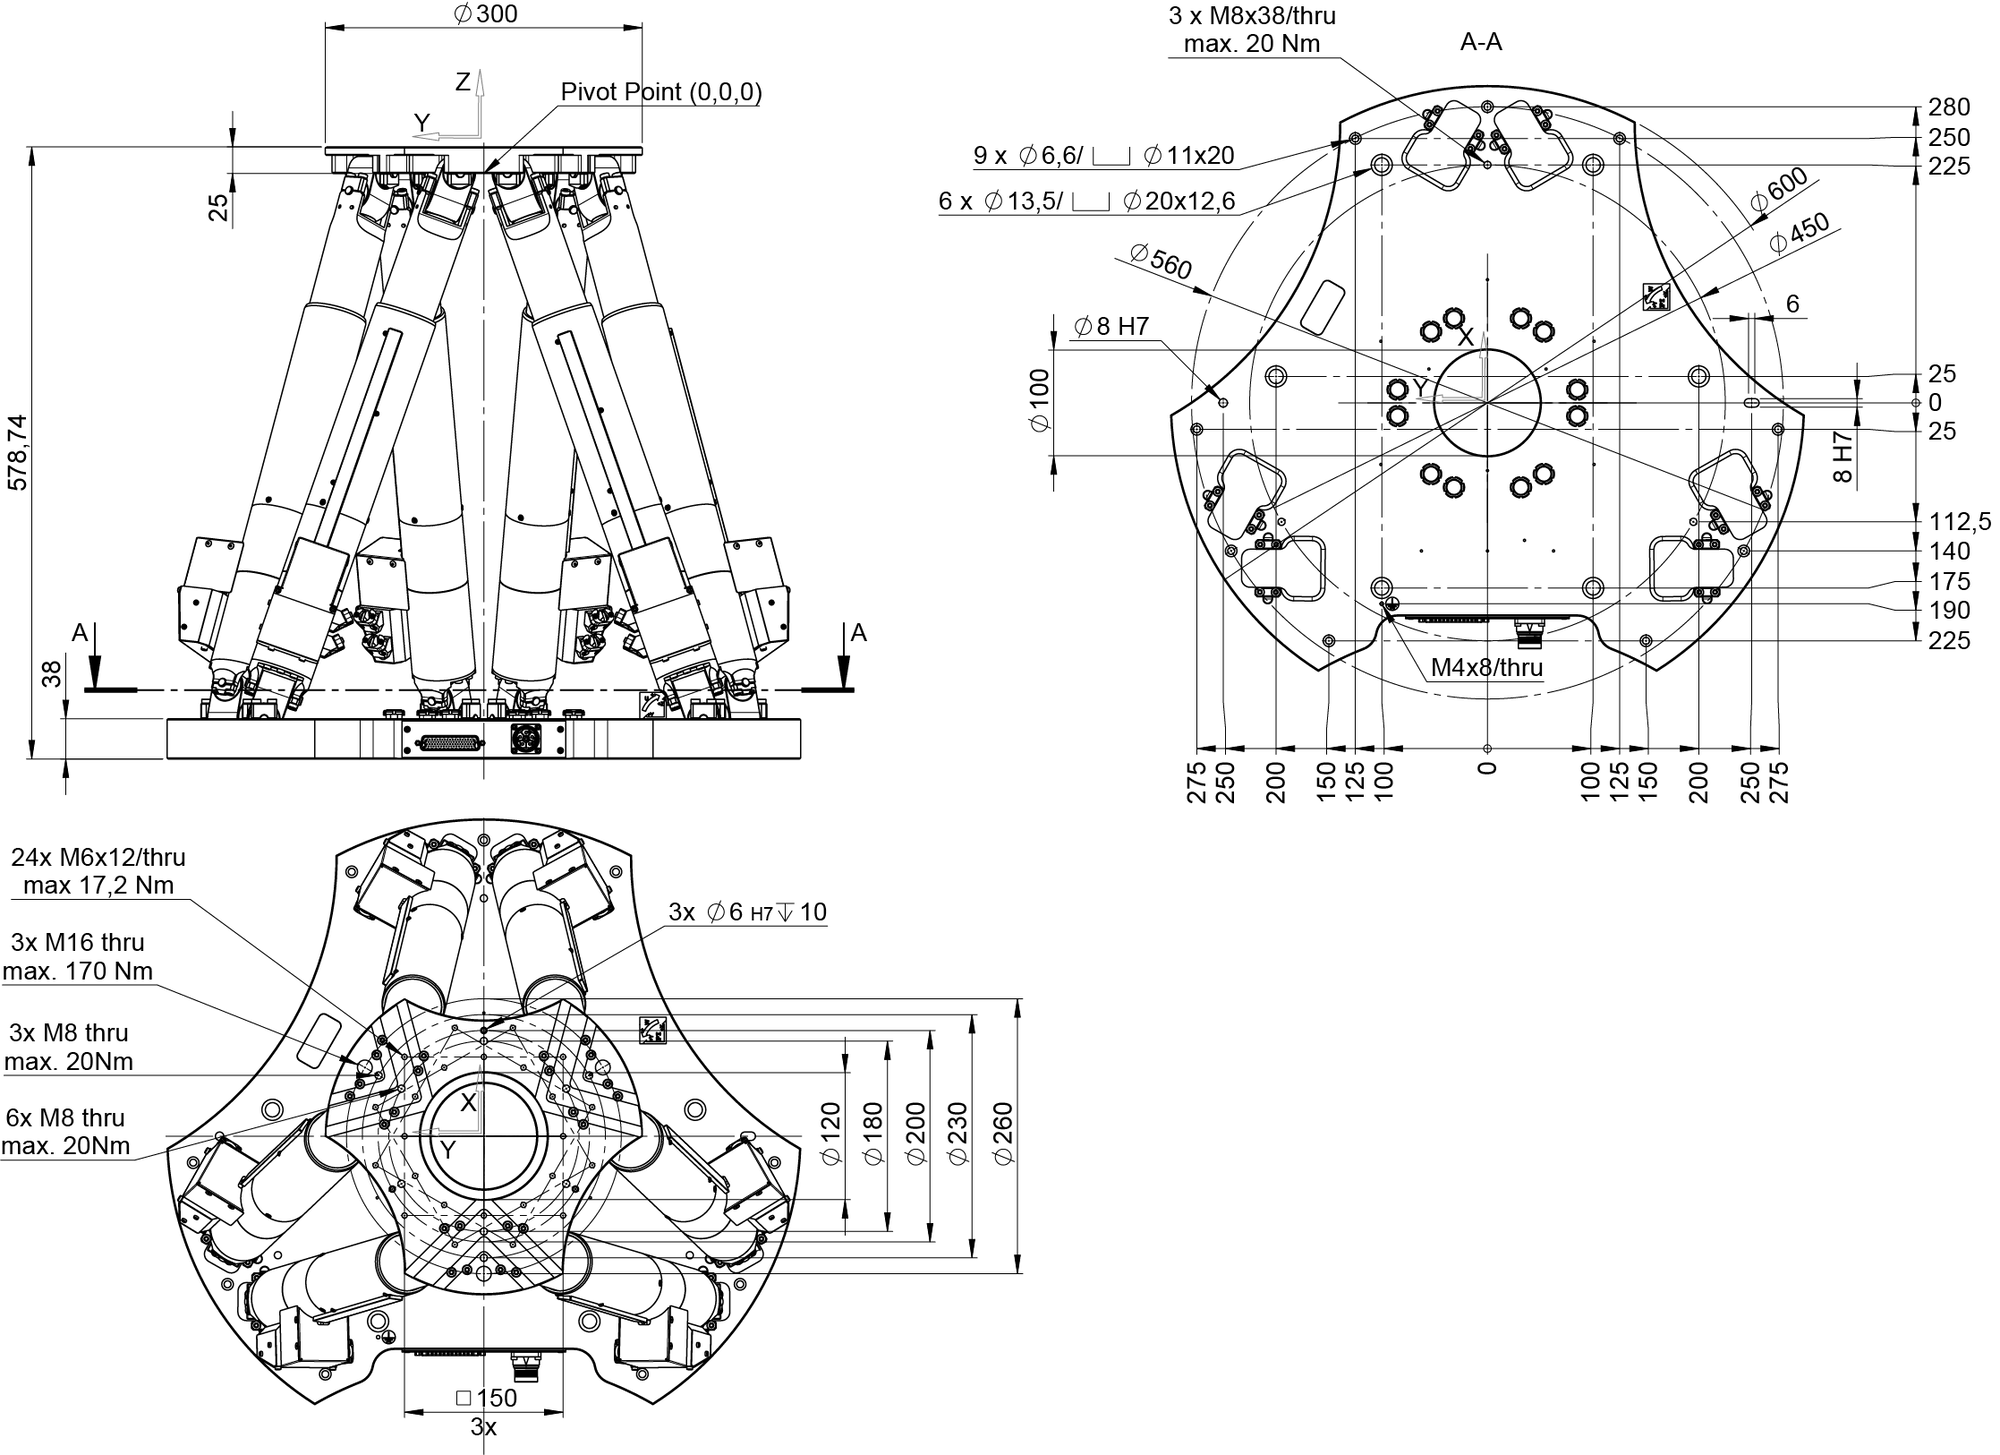
H-855.H2AL, dimensions in mm, at the zero position of the nominal travel range
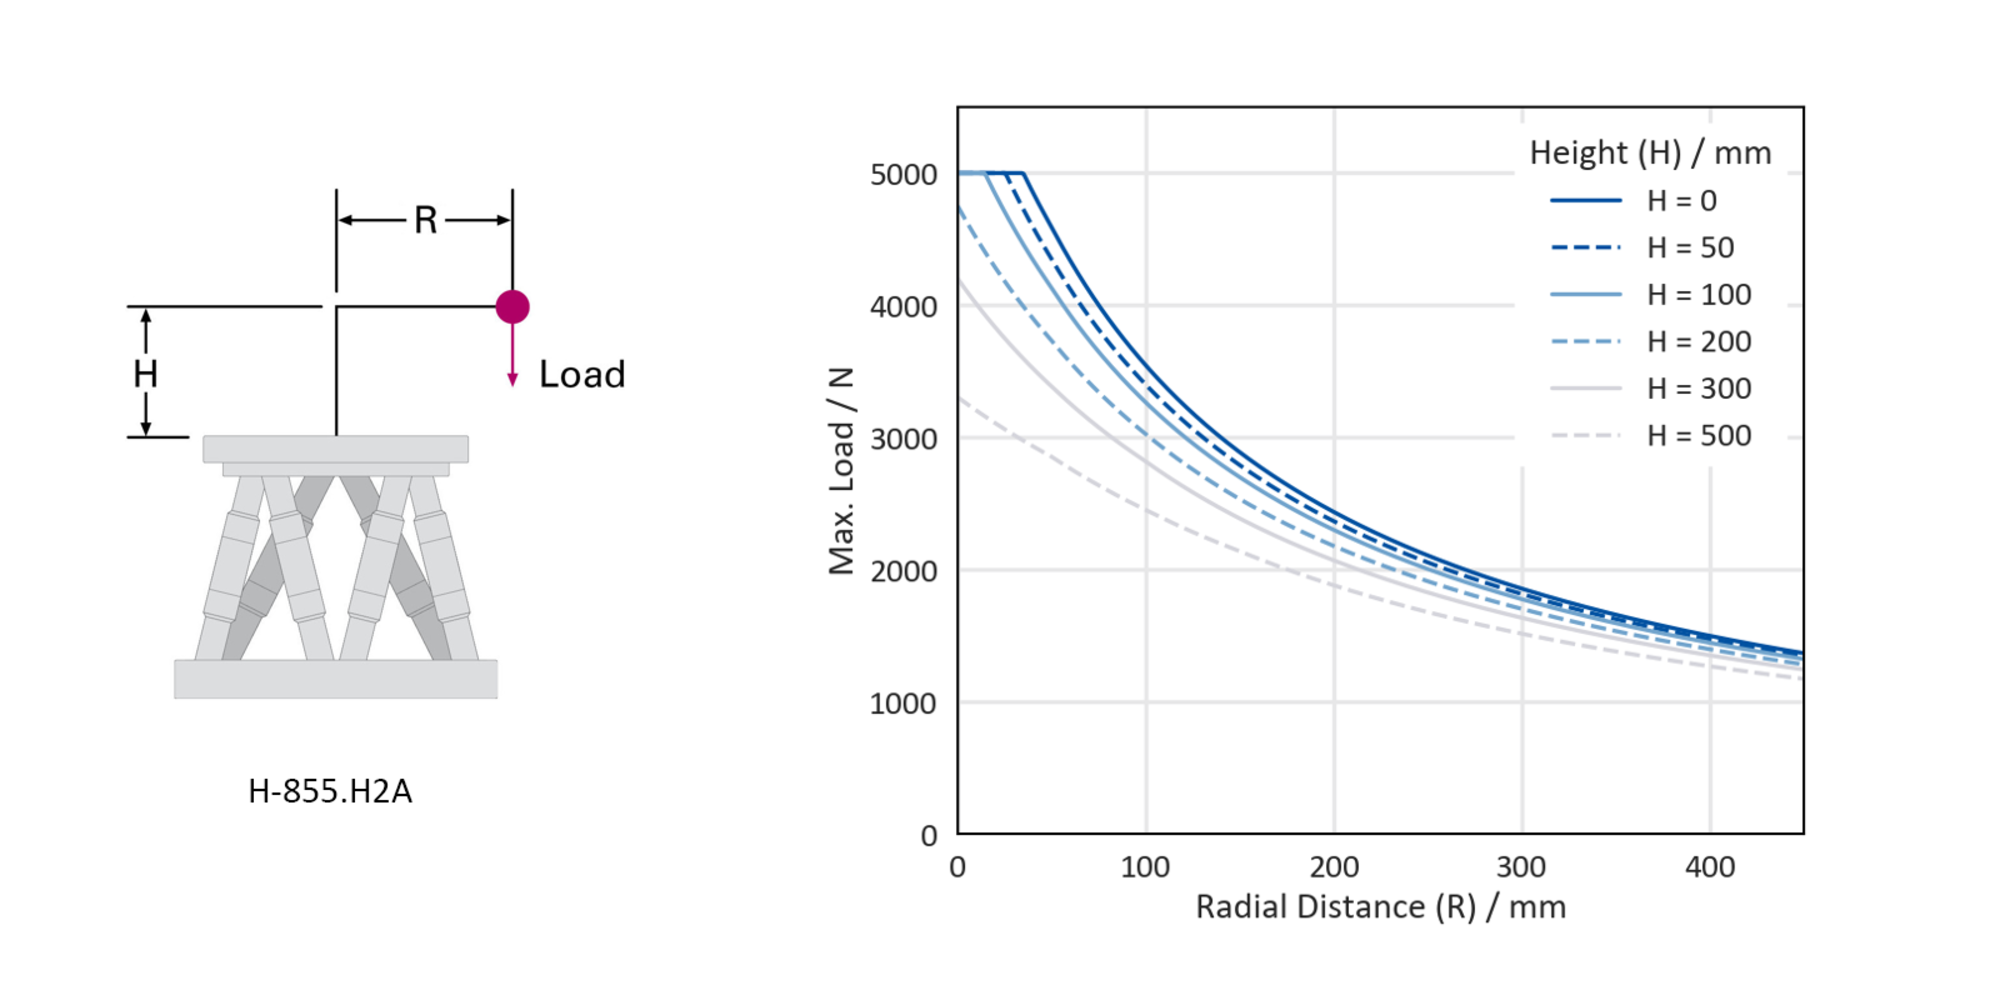
Maximum loads on the H-855.H2A when mounted horizontally
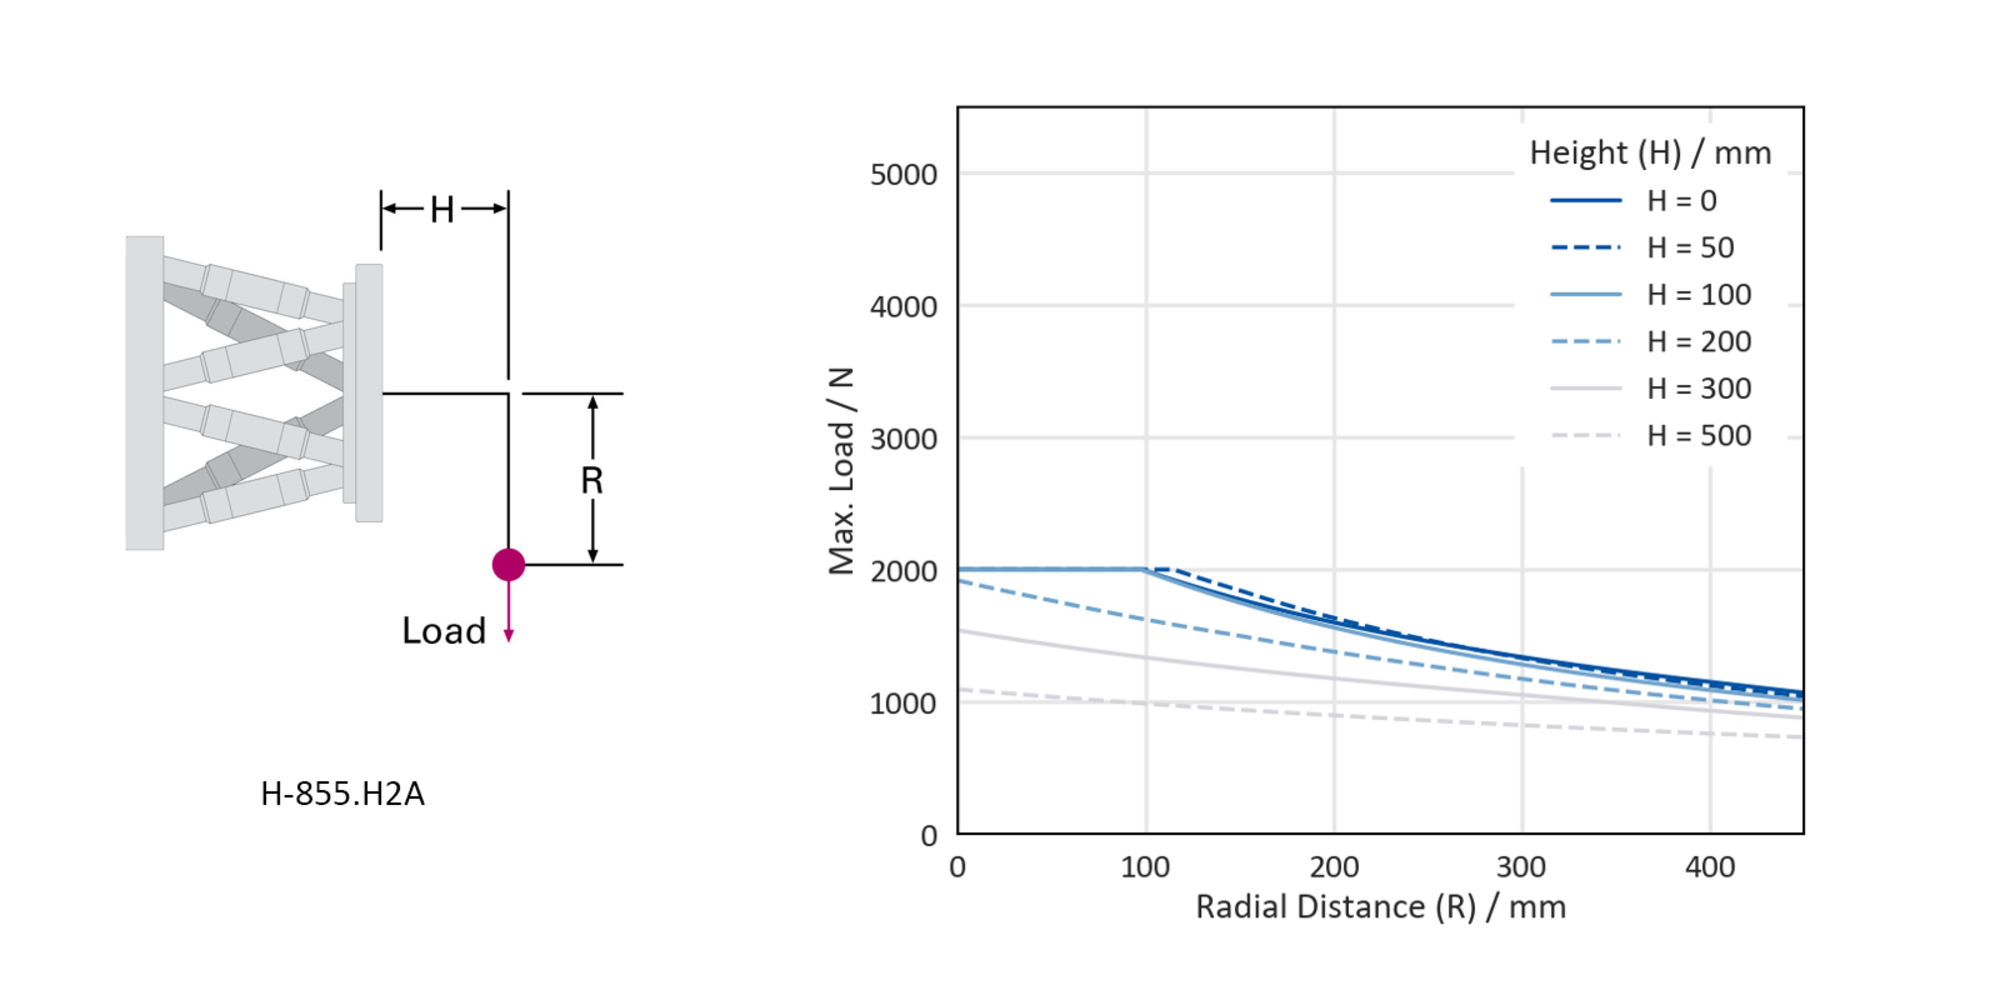
Maximum loads on the H-855.H2A when mounted vertically
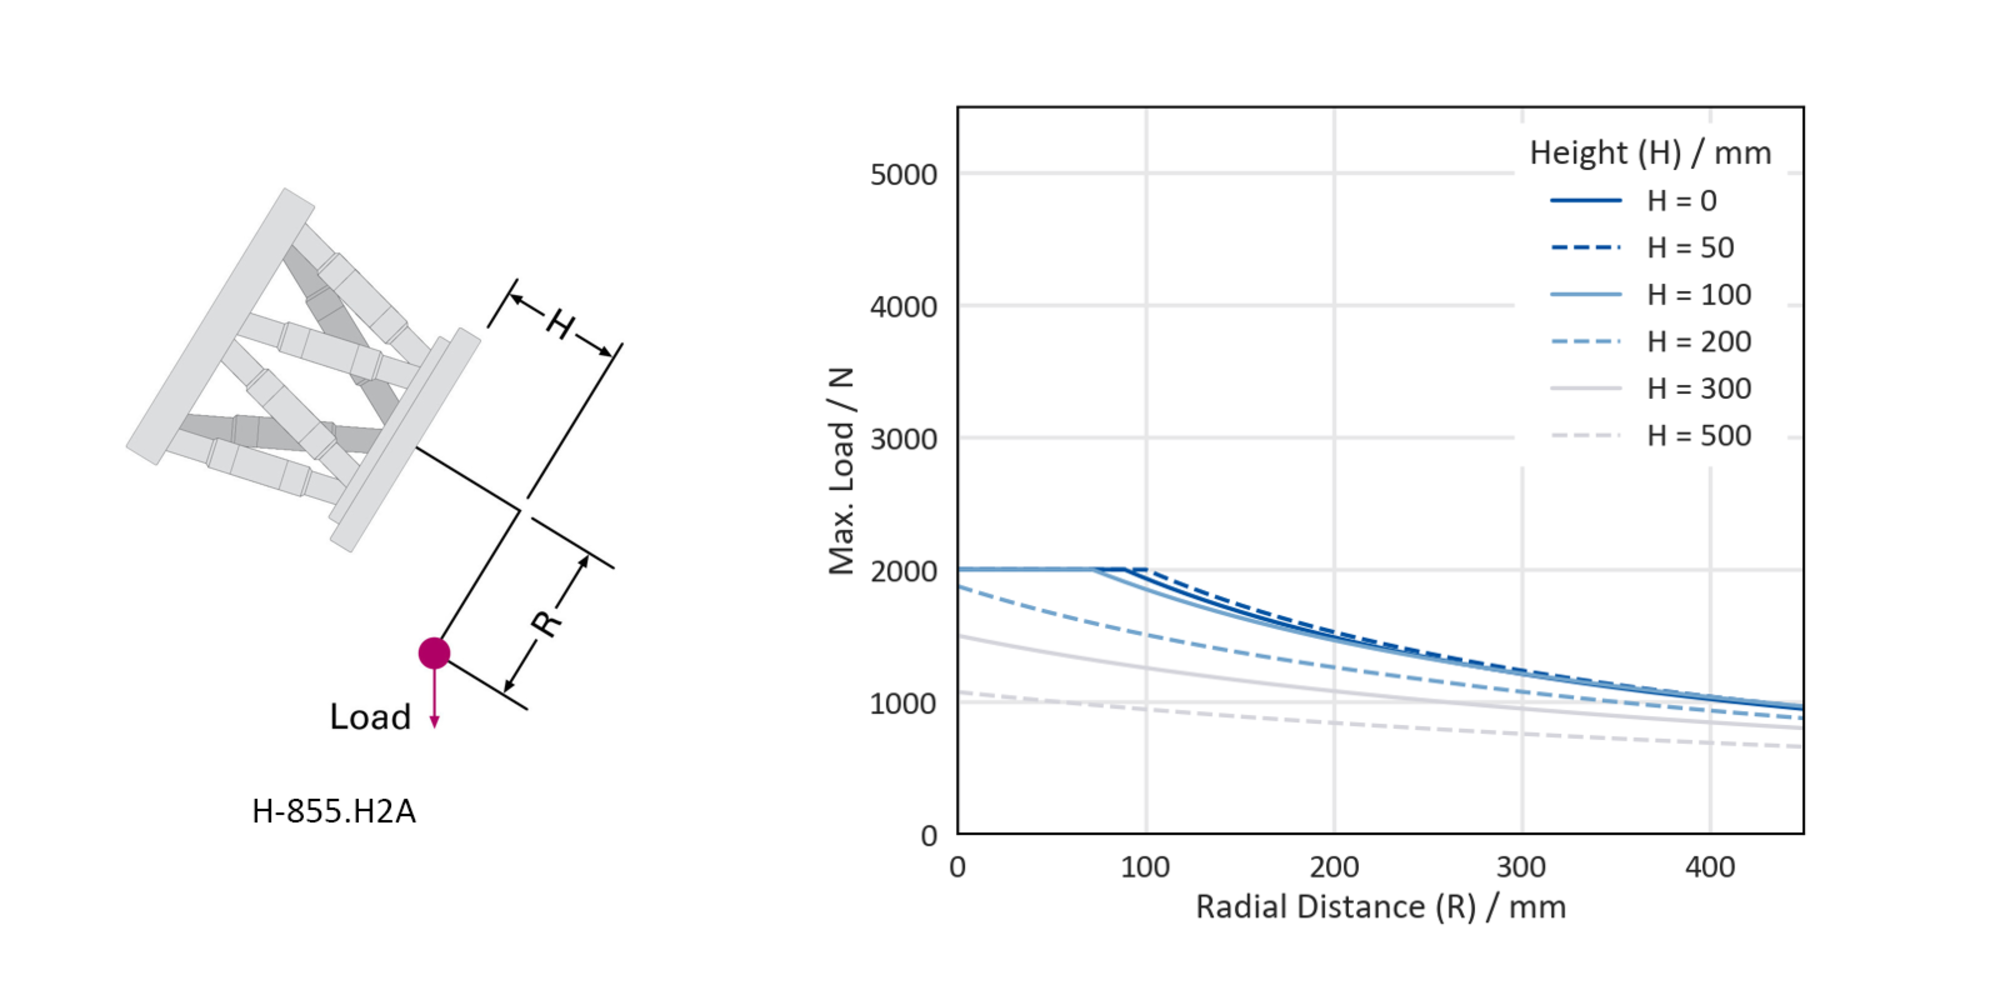
Maximum loads on the H-855.H2A when mounted at the most unfavorable angle
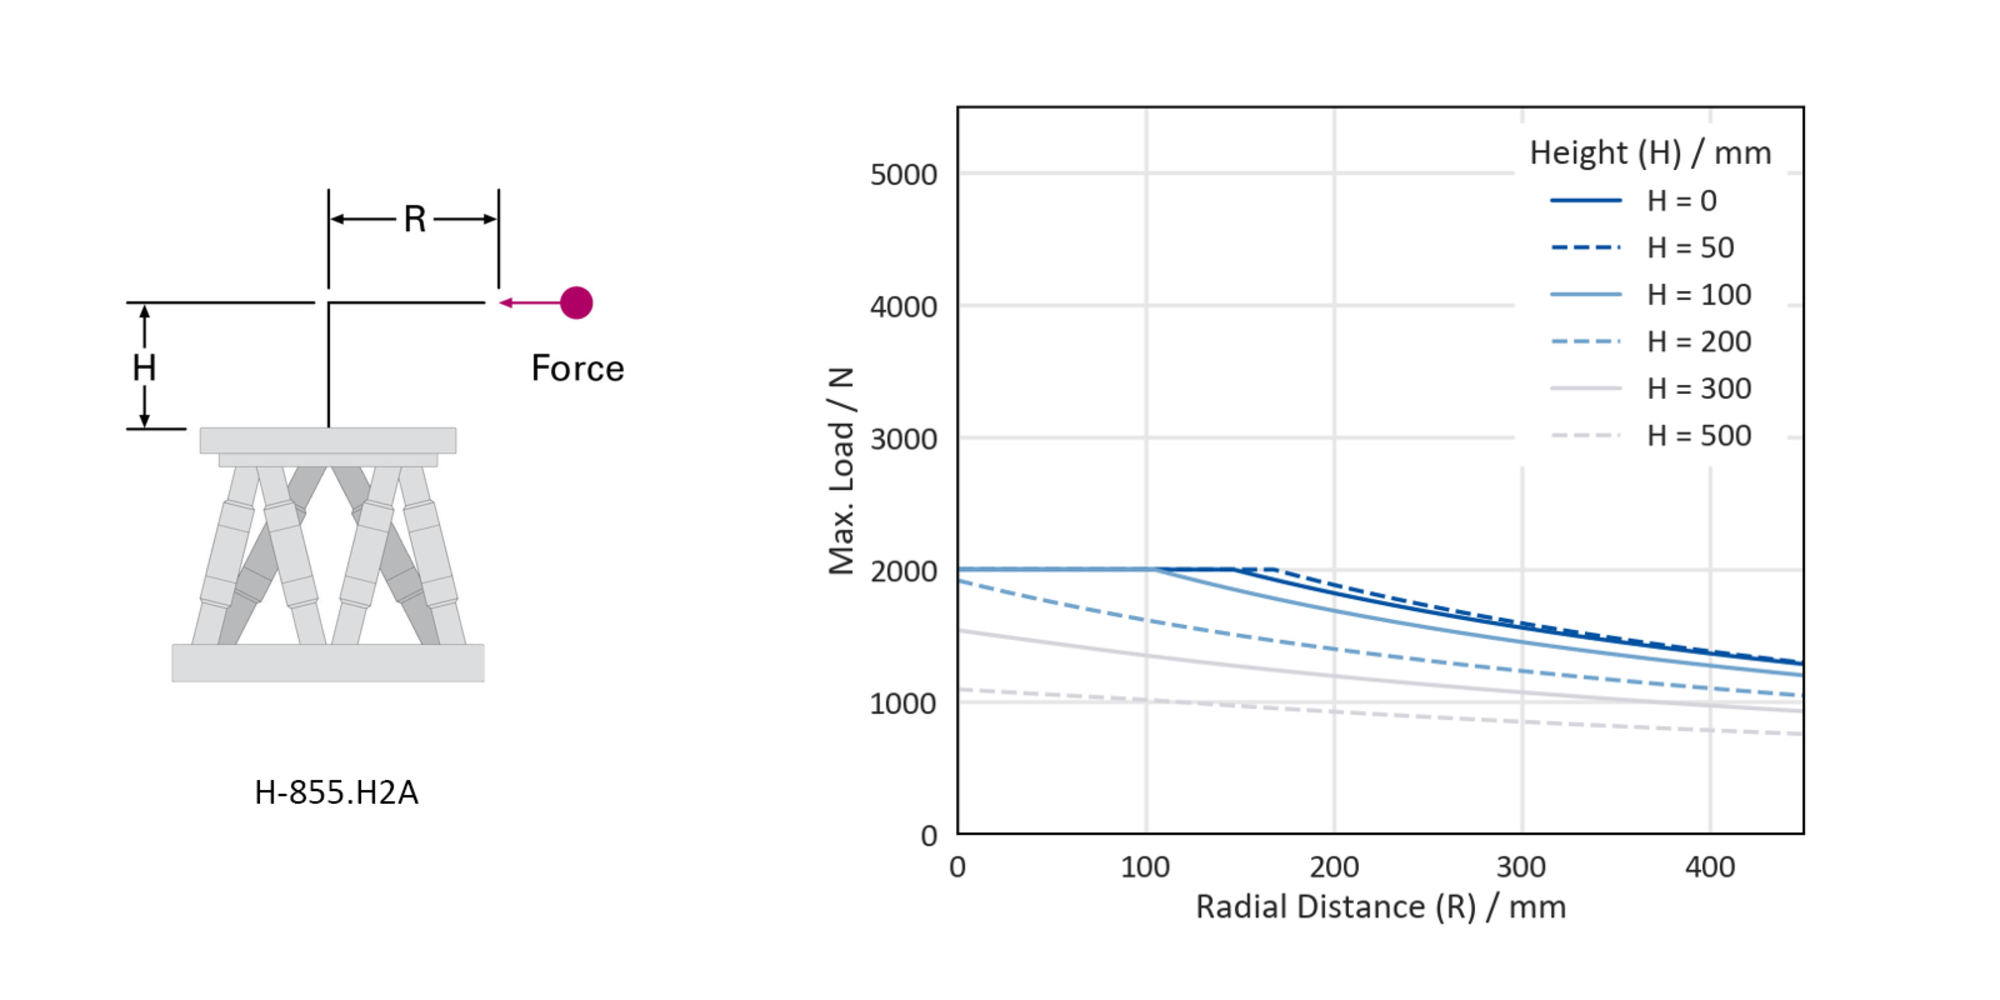
Maximum permissible force acting on the H-855.H2A when mounted horizontally


The modular H-855 high-load hexapod is a high-precision 6-axis positioning system designed for industrial automation, optics, semiconductor technology, aerospace, and simulation applications with payloads of up to 500 kg. Its modular architecture combines sub-micron accuracy, high load capacity, and customizable travel ranges and dynamic performance, enabling reliable positioning even under demanding operating conditions.
Fields of application
To deliver the optimal solution for specific customer applications, the H-855 is available in four optimized product variants, each tailored to different performance priorities:
The standard H-855.H2A model is optimized for high precision and payloads up to 500 kg. This makes it ideal for demanding positioning and alignment tasks involving heavy components.
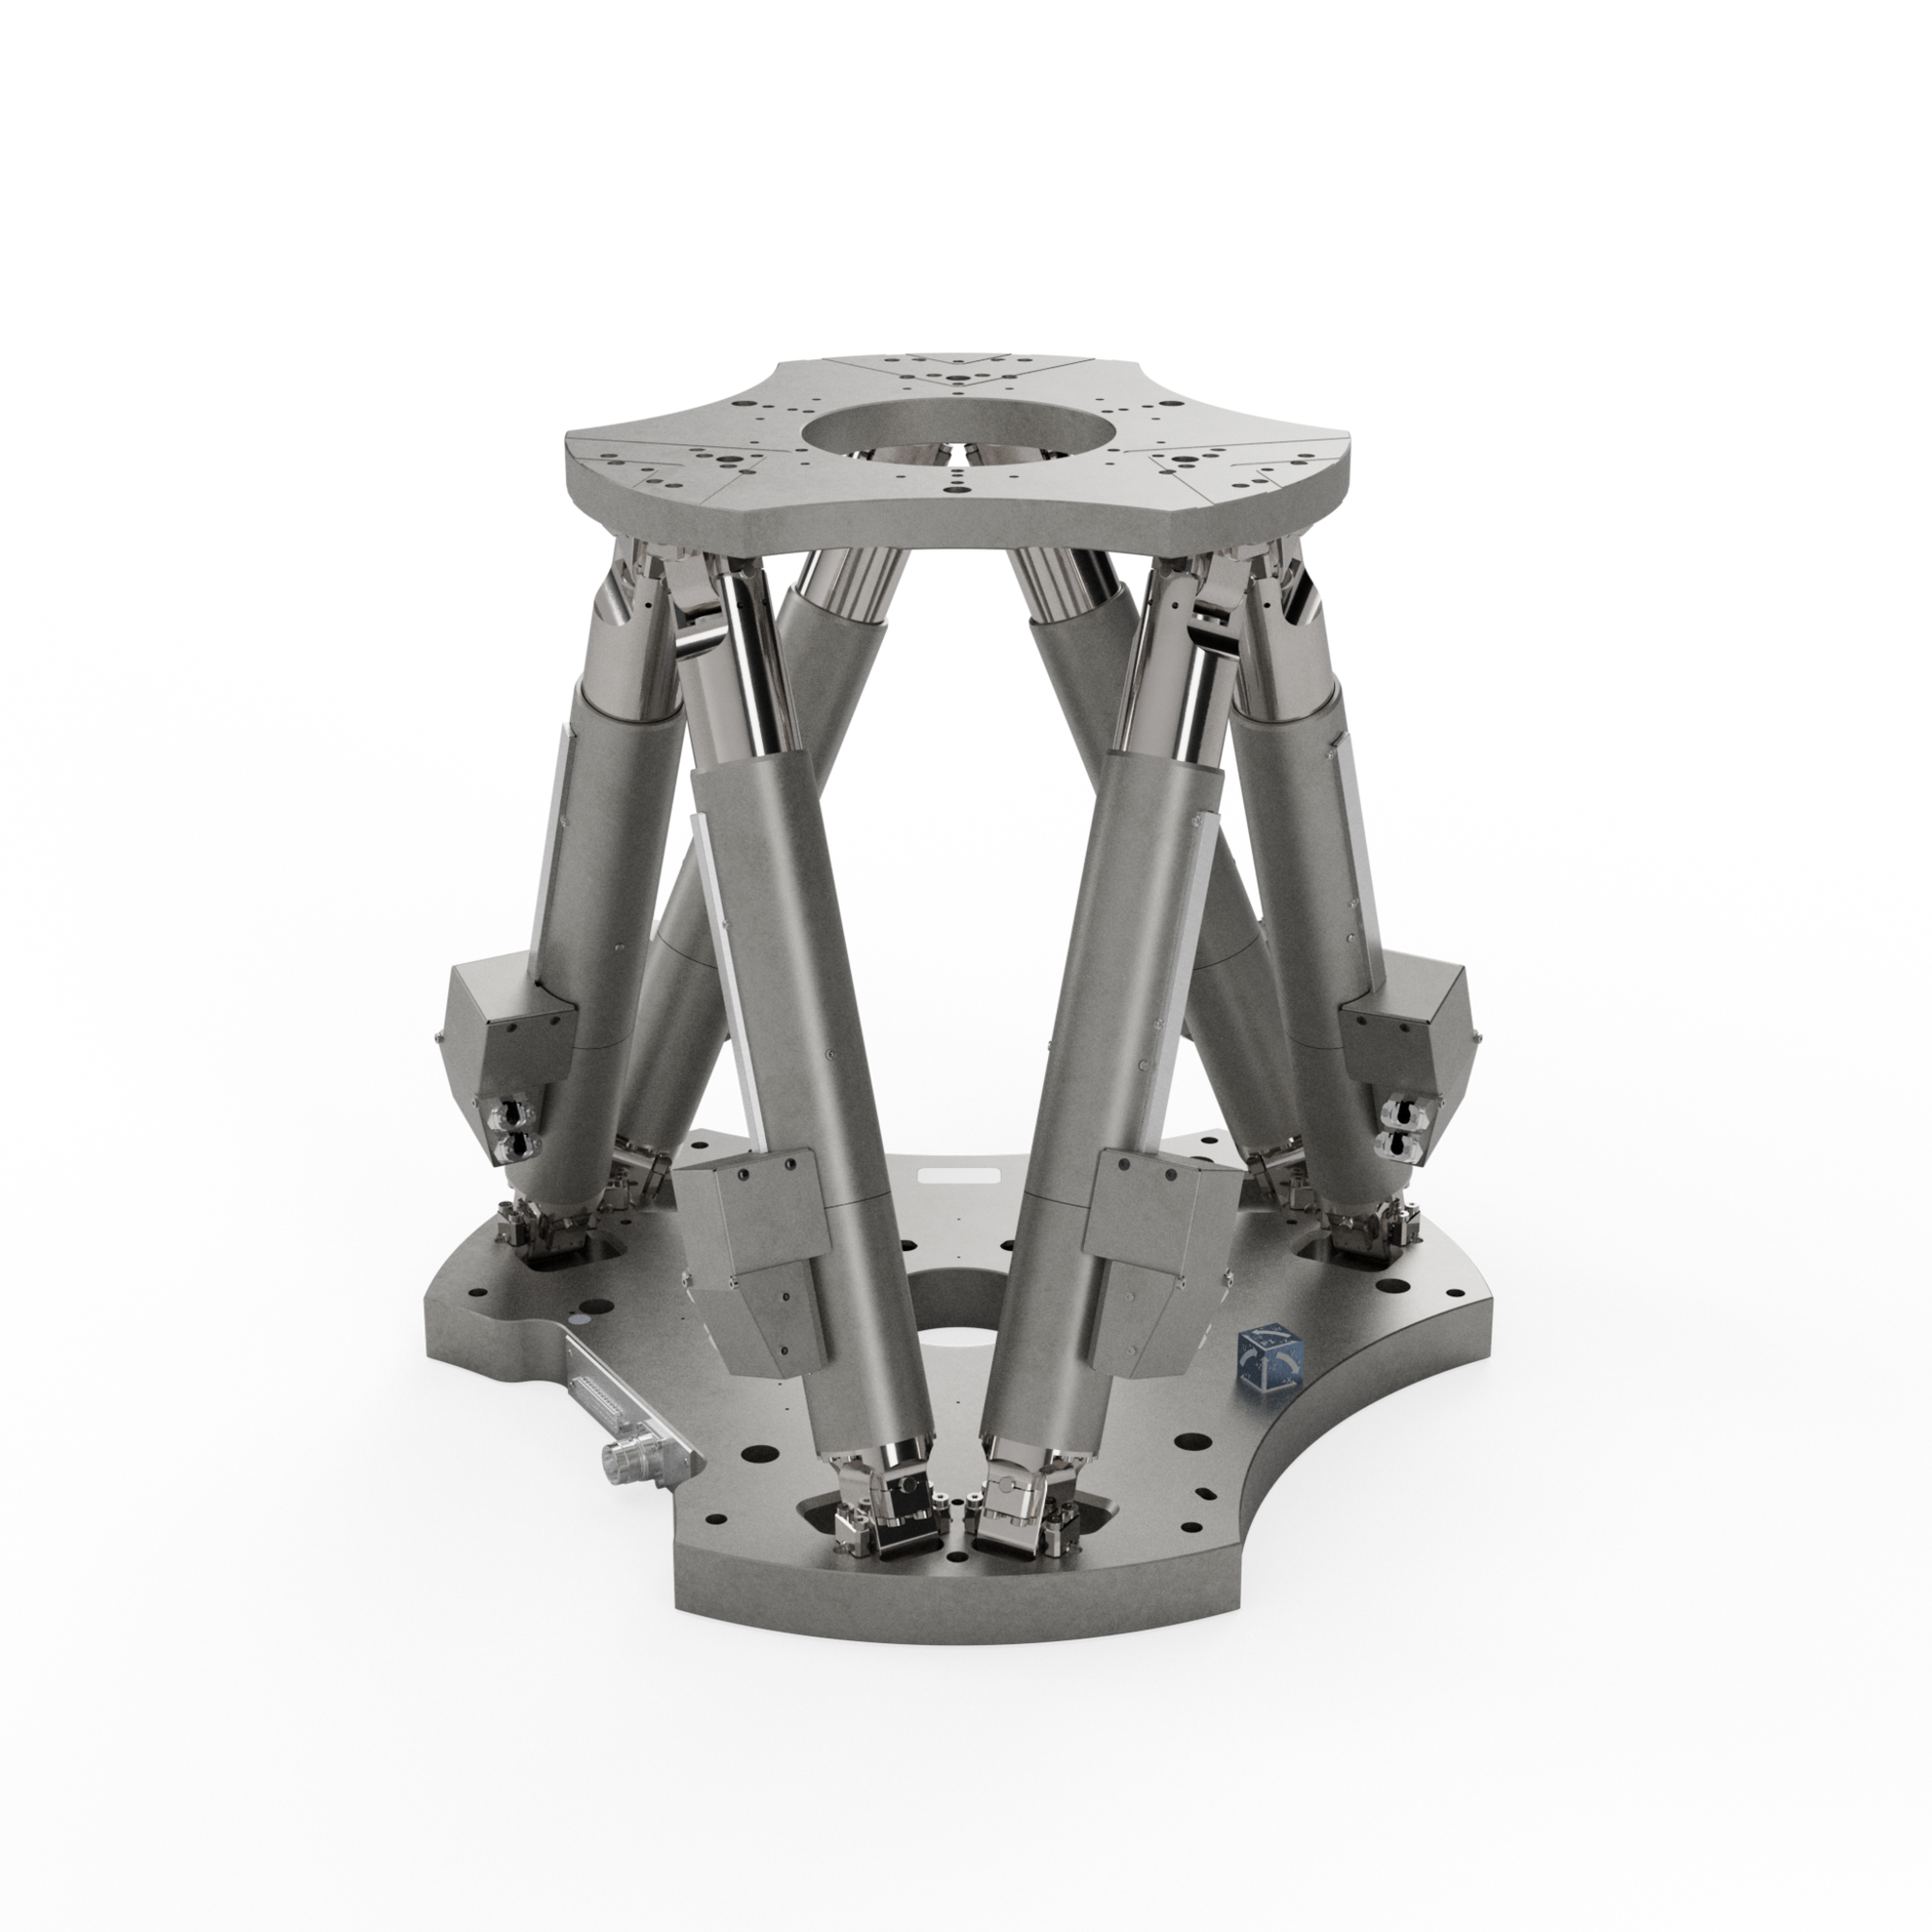
The 'fastest' version (H-855.G2A0B) was developed for high-throughput applications and achieves velocities of up to 10 mm/s. Its integrated brake enhances process reliability and ensures a stable holding position, making it ideal for dynamic industrial processes where cycle time is critical.
The 'smallest' version (H-855.H2AC) features a compact design with folded legs, reduced installation height, and smaller upper and lower platform dimensions. This enables integration into systems with limited installation space as well as laboratory environments.
For applications that require larger motion ranges, the version with the maximum travel range (H-855.H2AL) offers extended translational and rotational travel. It enables particularly flexible positioning and is suitable for demanding simulation tasks.
Within the modular architecture, custom variants can be created to tailor the hexapod to specific requirements.
Technology
The H-855 is based on a parallel-kinematic hexapod design, where 6 coordinated actuators simultaneously control motion along all translational and rotational axes. This architecture enables highly dynamic and precise positioning while efficiently distributing mechanical loads throughout the system. Compared with conventional serial-kinematic positioning systems, the parallel structure delivers higher stiffness, a better load-capacity-to-size ratio, and reduced cumulative positioning errors.
The H-855 hexapod uses brushless DC gear motors in combination with absolute rotary encoders. This guarantees stable motion control and reliable position feedback. Since the rotary encoders provide absolute position data immediately after power-up, no referencing or homing move is required. This reduces startup time and enhances operational reliability in automated environments.
Another technological advantage is the scalable modular architecture. Within the same system architecture, various actuator configurations, gear ratios, travel ranges, and geometries can be combined. This allows the hexapod to be optimized for specific applications without having to redesign the entire product. Users can configure velocity, compactness, travel range, holding force, and payload capacity according to the specific requirements of each application.
Electronics and software
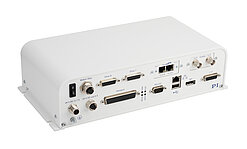
Controller: C-887.5x0
Software: PIMikroMove
Important note regarding the H-855: The hexapod has a separate power supply, as the motors require more power than the controller can provide.
Motion | Unit |
| H-855.H2A | H-855.H2AC* | H-855.H2AL* | H-855.G2A0B* |
|---|---|---|---|---|---|---|
Active axes |
|
| X ǀ Y ǀ Z ǀ θX ǀ θY ǀ θZ | X ǀ Y ǀ Z ǀ θX ǀ θY ǀ θZ | X ǀ Y ǀ Z ǀ θX ǀ θY ǀ θZ | X ǀ Y ǀ Z ǀ θX ǀ θY ǀ θZ |
Travel range in X | mm |
| ±100 | ±100 | ±50 | ±160 |
Travel range in Y | mm |
| ±100 | ±100 | ±50 | ±160 |
Travel range in Z | mm |
| ±50 | ±50 | ±25 | ±75 |
Rotation range in θX | ° |
| ±25 | ±18 | ±12 | ±27 |
Rotation range in θY | ° |
| ±25 | ±18 | ±12 | ±27 |
Rotation range in θZ | ° |
| ±40 | ±35 | ±25 | ±60 |
Maximum velocity in X, Y, Z | mm/s |
| 0.5 | 10 | 1 | 2.5 |
Typical velocity in X, Y, Z | mm/s |
| 0.3 | 6 | 0.6 | 1.5 |
Positioning | Unit | Tolerance | H-855.H2A | H-855.H2AC* | H-855.H2AL* | H-855.G2A0B* |
|---|---|---|---|---|---|---|
Minimum incremental motion in X | µm | typ. | 0.3 | 4.5 | 0.6 | 1.5 |
Minimum incremental motion in Y | µm | typ. | 0.3 | 4.5 | 0.6 | 1.5 |
Minimum incremental motion in Z | µm | typ. | 0.15 | 2.2 | 0.3 | 0.8 |
Unidirectional repeatability in X | µm | typ. | 0.4 | 4.5 | 0.6 | 1.5 |
Unidirectional repeatability in Y | µm | typ. | 0.4 | 4.5 | 0.6 | 1.5 |
Unidirectional repeatability in Z | µm | typ. | 0.15 | 2.2 | 0.3 | 0.7 |
Backlash in X | µm | typ. | 4 | 16 | 6 | 12 |
Backlash in Y | µm | typ. | 4 | 16 | 6 | 12 |
Backlash in Z | µm | typ. | 1 | 4 | 1.5 | 3 |
Integrated sensor |
|
| Absolute rotary encoder | Absolute rotary encoder | Absolute rotary encoder | Absolute rotary encoder |
Mechanical properties | Unit | Tolerance | H-855.H2A | H-855.H2AC* | H-855.H2AL* | H-855.G2A0B* |
|---|---|---|---|---|---|---|
Stiffness in X | N/µm | ± 20 % | 4 | 4 | 4 | 2.5 |
Stiffness in Y | N/µm | ± 20 % | 4 | 4 | 4 | 2.5 |
Stiffness in Z | N/µm | ± 20 % | 50 | 50 | 50 | 55 |
Maximum load capacity, base plate horizontal | kg | max. | 500 | 260 | 400 | 300 |
Maximum load capacity, base plate in any orientation | kg | max. | 200 | 120 | 150 | 200 |
Maximum holding force, passive, base plate horizontal | N | max. | 5000 | 2600 | 4000 | 3000 |
Maximum holding force, passive, base plate in any orientation | N | max. | 2000 | 1200 | 1500 | 2000 |
Overall mass | kg | ±10 % | 45 | - | - | - |
Material |
|
| Aluminum | Aluminum | Aluminum | Aluminum |
Miscellaneous | Unit |
| H-855.H2A | H-855.H2AC* | H-855.H2AL* | H-855.G2A0B* |
|---|---|---|---|---|---|---|
Operating temperature range | °C |
| -10 to +50 | -10 to +50 | -10 to +50 | -10 to +50 |
Connector for data transmission |
|
| HD D-sub 78 (m) | HD D-sub 78 (m) | HD D-sub 78 (m) | HD D-sub 78 (m) |
Connector for supply voltage |
|
| M23 6-pin (m) | M23 6-pin (m) | M23 6-pin (m) | M23 6-pin (m) |
Recommended controllers/drivers |
|
| C-887.5x0 | C-887.5x0 | C-887.5x0 | C-887.5x0 |
* The specifications for the H-855.H2AC, H-855.H2AL, and H-855.G2A0B variants are preliminary; metrological verification is pending.
When measuring position specifications, typical velocity is used. The data is included in the delivery of the product in the form of a measurement report and is stored at PI.
The maximum travel ranges of the individual coordinates (X, Y, Z, θX, θY, θZ) are interdependent. The data for each axis shows its maximum travel range when all other axes are in the zero position of the nominal travel range and the default coordinate system is in use, or rather when the pivot point is set to 0,0,0.
At PI, technical data is specified at 22 ±3 °C. Unless otherwise stated, the values are for unloaded conditions. Some properties are interdependent. The designation "typ." indicates a statistical average for a property; it does not indicate a guaranteed value for every product supplied. During the final inspection of a product, only selected properties are analyzed, not all. Please note that some product characteristics may deteriorate with increasing operating time.
Ask for a free quote on quantities required, prices, and lead times or describe your desired modification.
High-load hexapod; brushless DC gear motor; absolute encoder; 500 kg payload; 0.5 mm/s maximum velocity; 3 m cable set consisting of data and power supply cables
High-load hexapod; brushless DC gear motor; absolute encoder; 400 kg payload; 1 mm/s maximum velocity; 3 m cable set consisting of data and power supply cables
High-load hexapod; brushless DC gear motor; absolute encoder; 300 kg payload; 2.5 mm/s maximum velocity; 3 m cable set consisting of data and power supply cables
High-load hexapod; brushless DC gear motor; absolute encoder; 260 kg payload; 10 mm/s maximum velocity; holding brake; 3 m cable set consisting of data and power supply cables
 Clicca su OFFERTA / ORDINE
 Aggiungi le alternative alla lista per l’offerta
 Compila il modulo offerta
 Invia una richiesta di prezzo a PI
 Vi contatteremo al più presto
Ricevere rapidamente una risposta alla tua risposta via email o telefono da un Sales Engineer dalla sede PI più vicina a te.